Stair Climbing Wheelchair
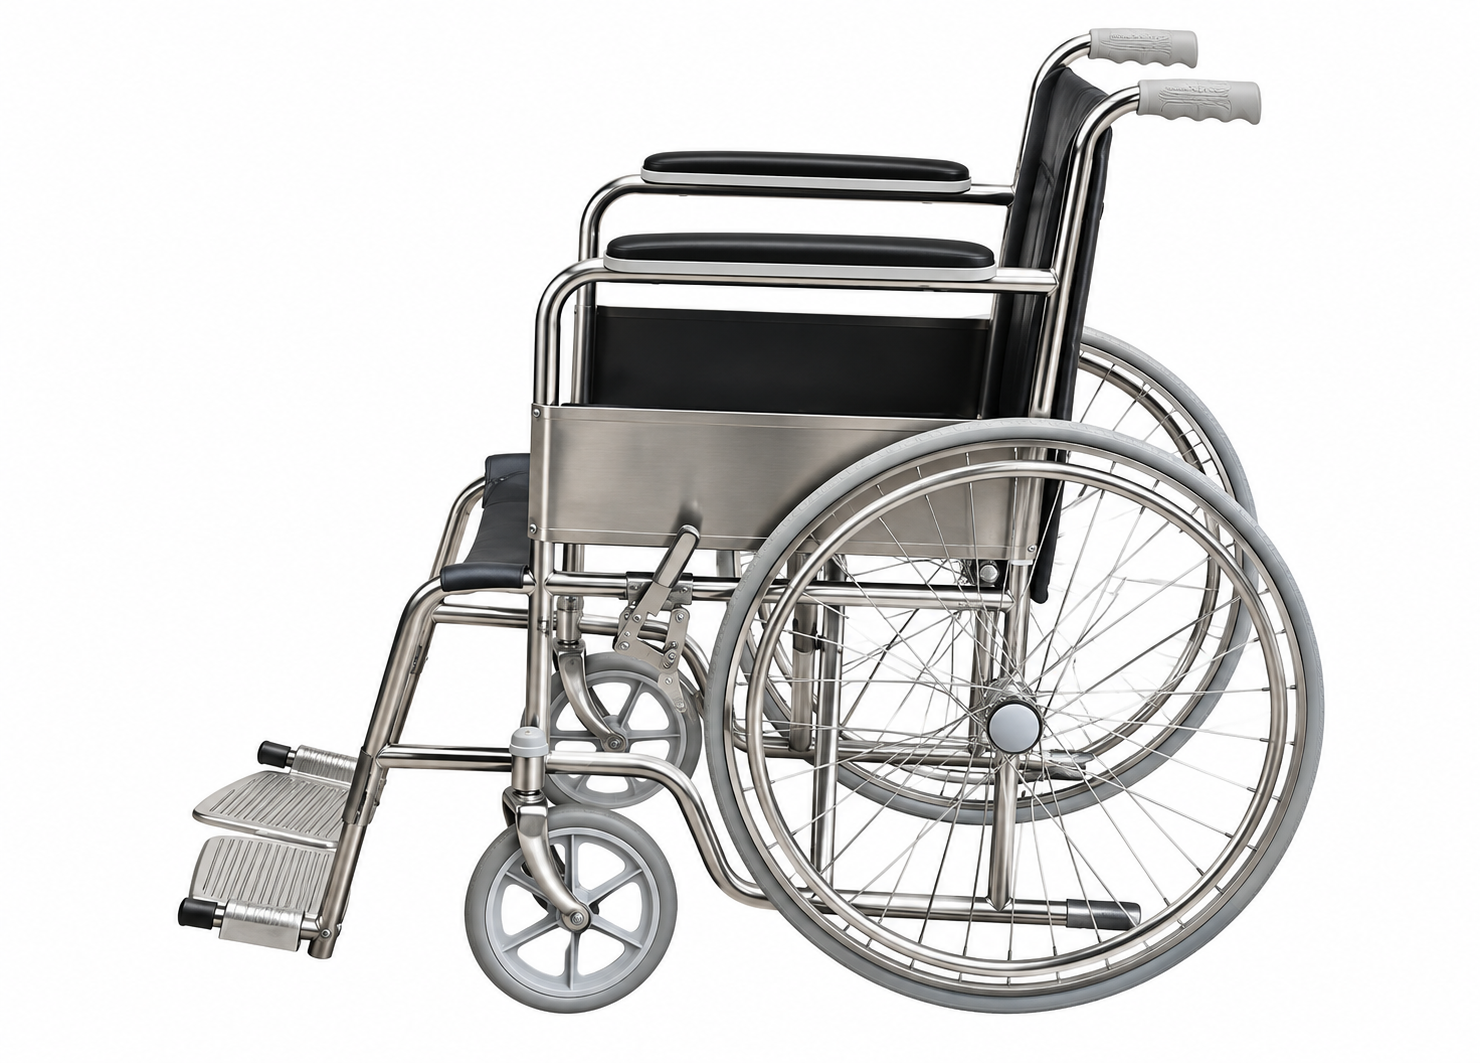
- Conventional wheelchairs are built primarily for flat surfaces and cannot independently navigate staircases.
- Existing stair-climbing wheelchairs can be expensive and complex, making them inaccessible to many users.
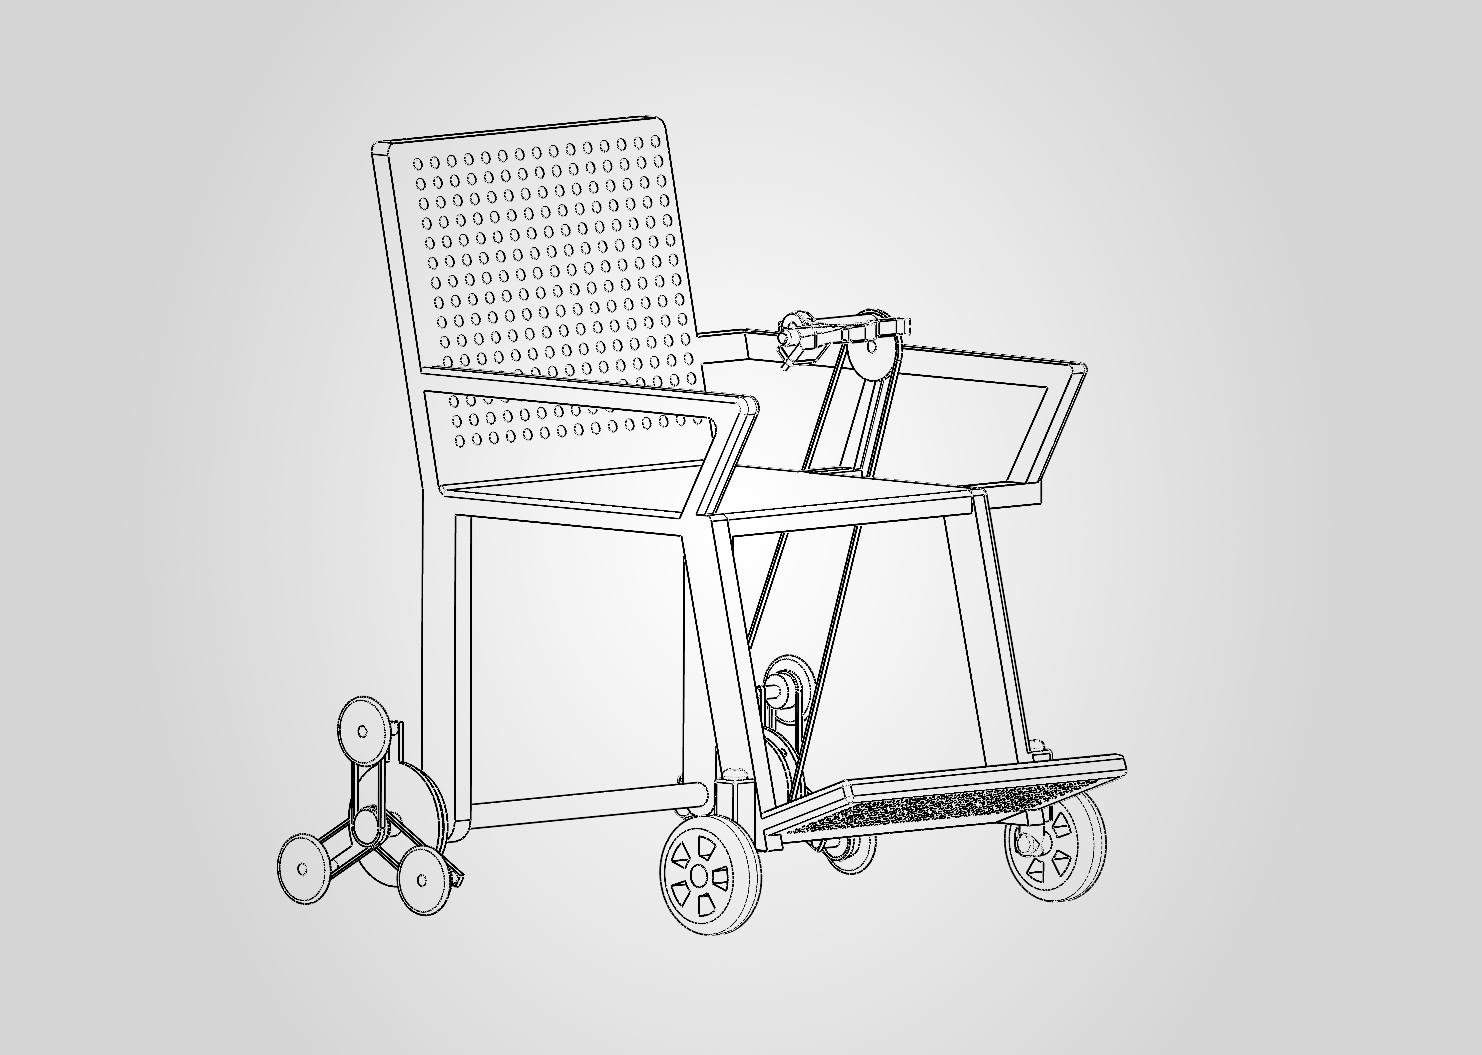
- Developed the CAD design of a stair-climbing wheelchair using a novel sun–planet gear mechanism for movement across flat surfaces and staircases.
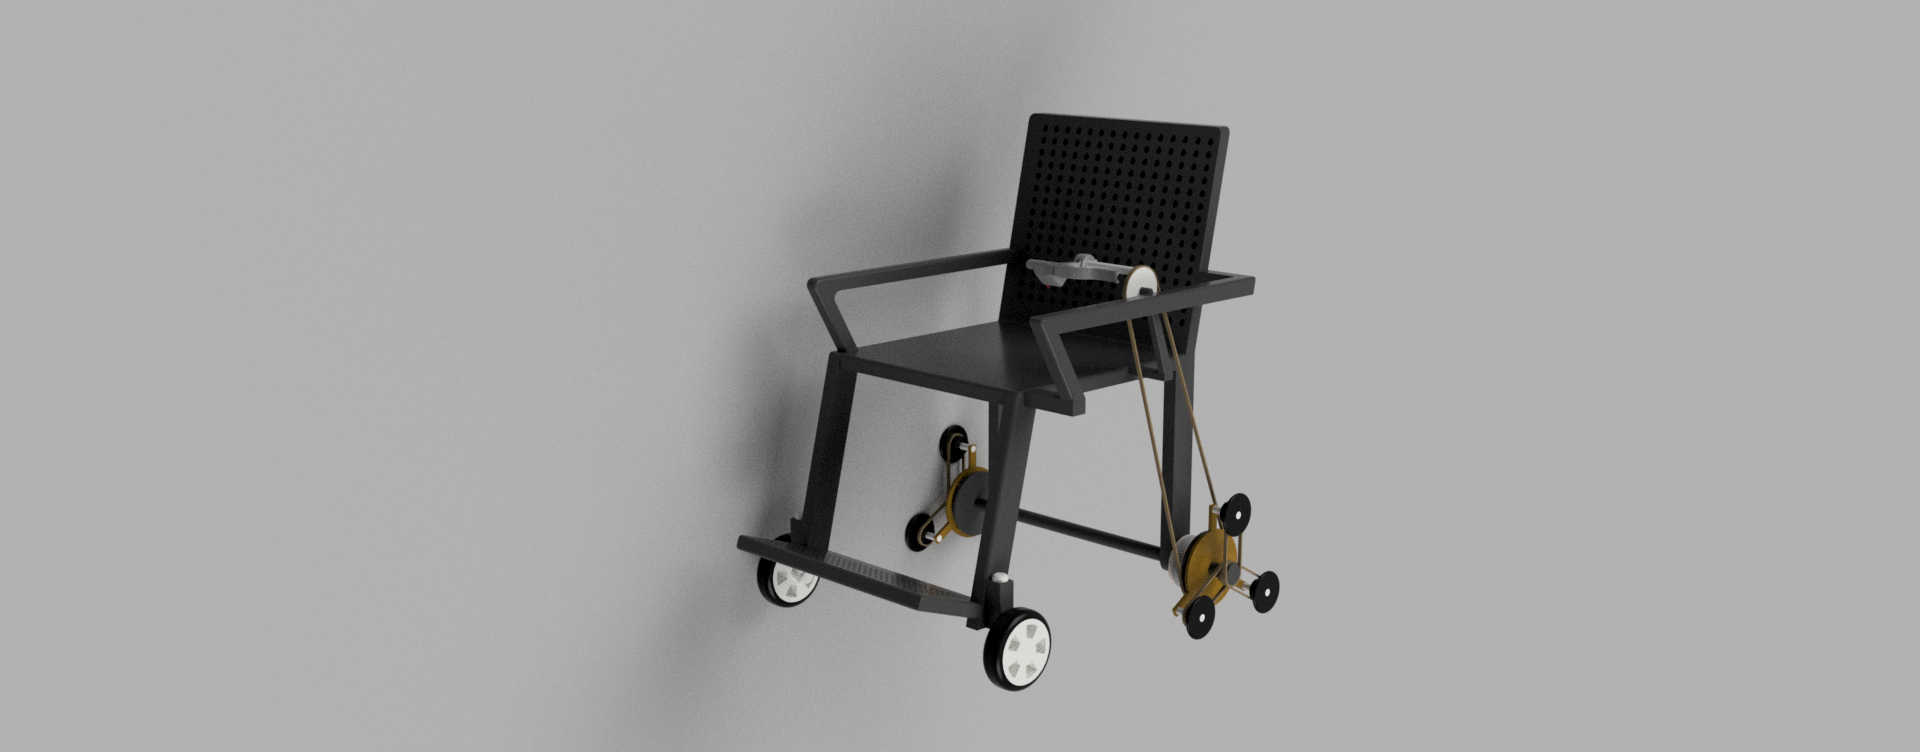
- Developed a mechanical concept for transitioning between flat-ground mobility and stair climbing.
- Focused on a lightweight, cost-effective alternative to conventional stair-climbing wheelchair systems.
Sun–Planet Gear System: Transmits hand-driven power to the rear wheels for movement on flat surfaces.
Lever-Based Mode Switching: Changes the mechanism from driving the wheels to rotating the planet carrier, enabling stair-climbing movement.
Forward–Backward Control: Uses the gear mechanism and lever-based mode selection to adapt movement between flat-ground travel and stair climbing, with a hydraulic disc brake for controlled stopping.
The Assembly
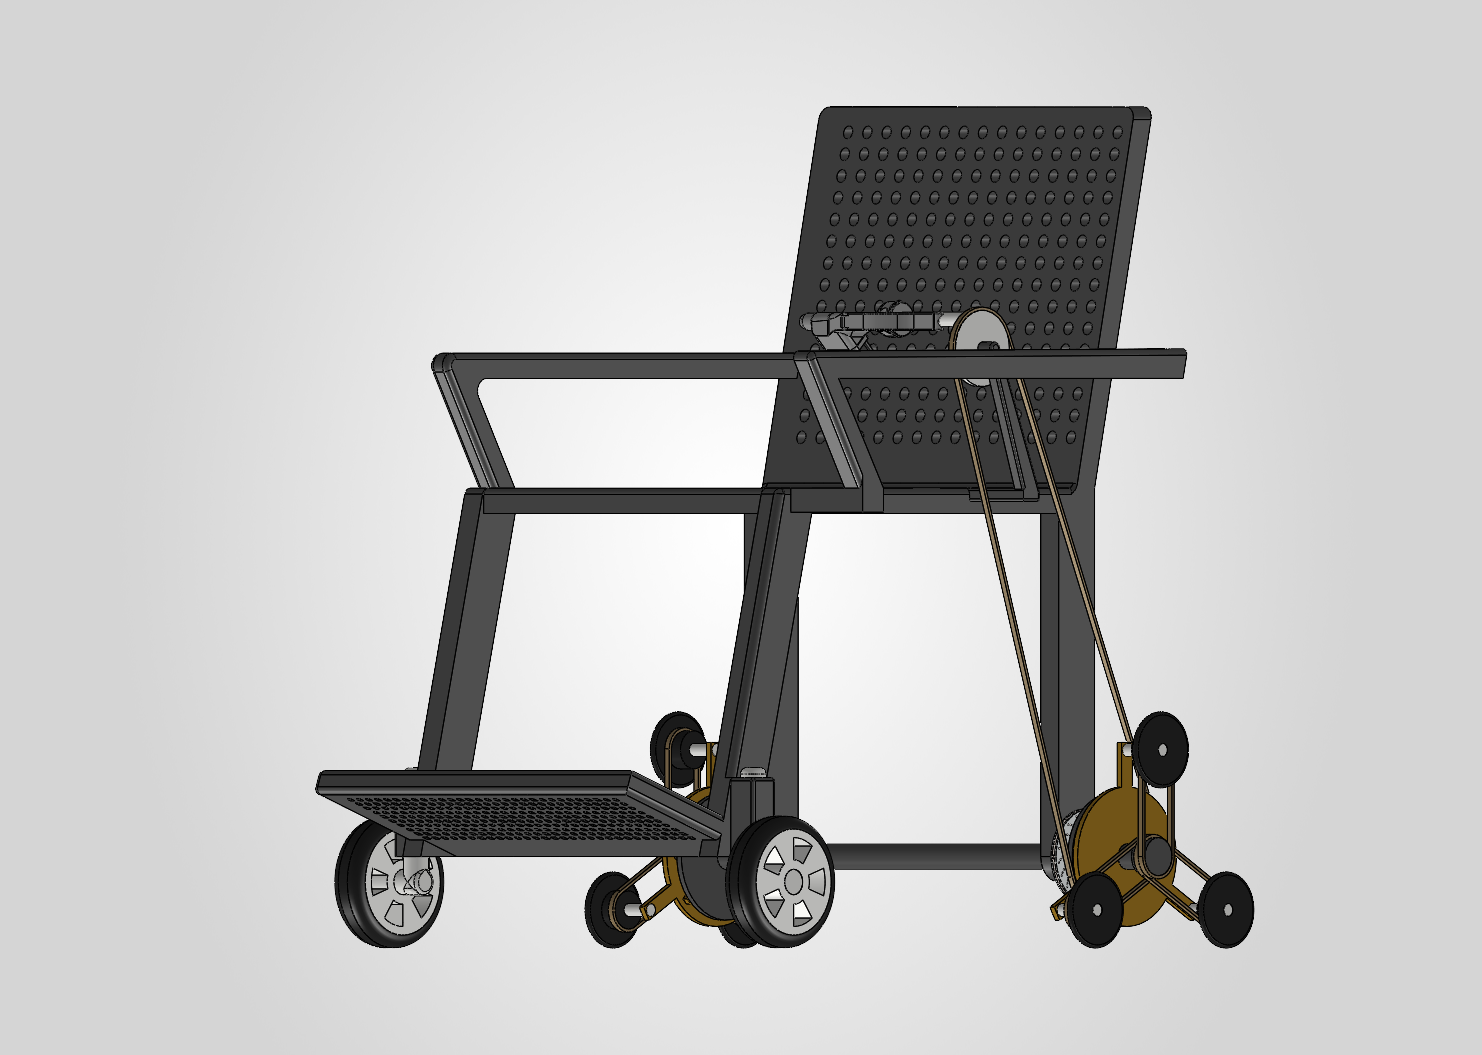
Component Breakdown
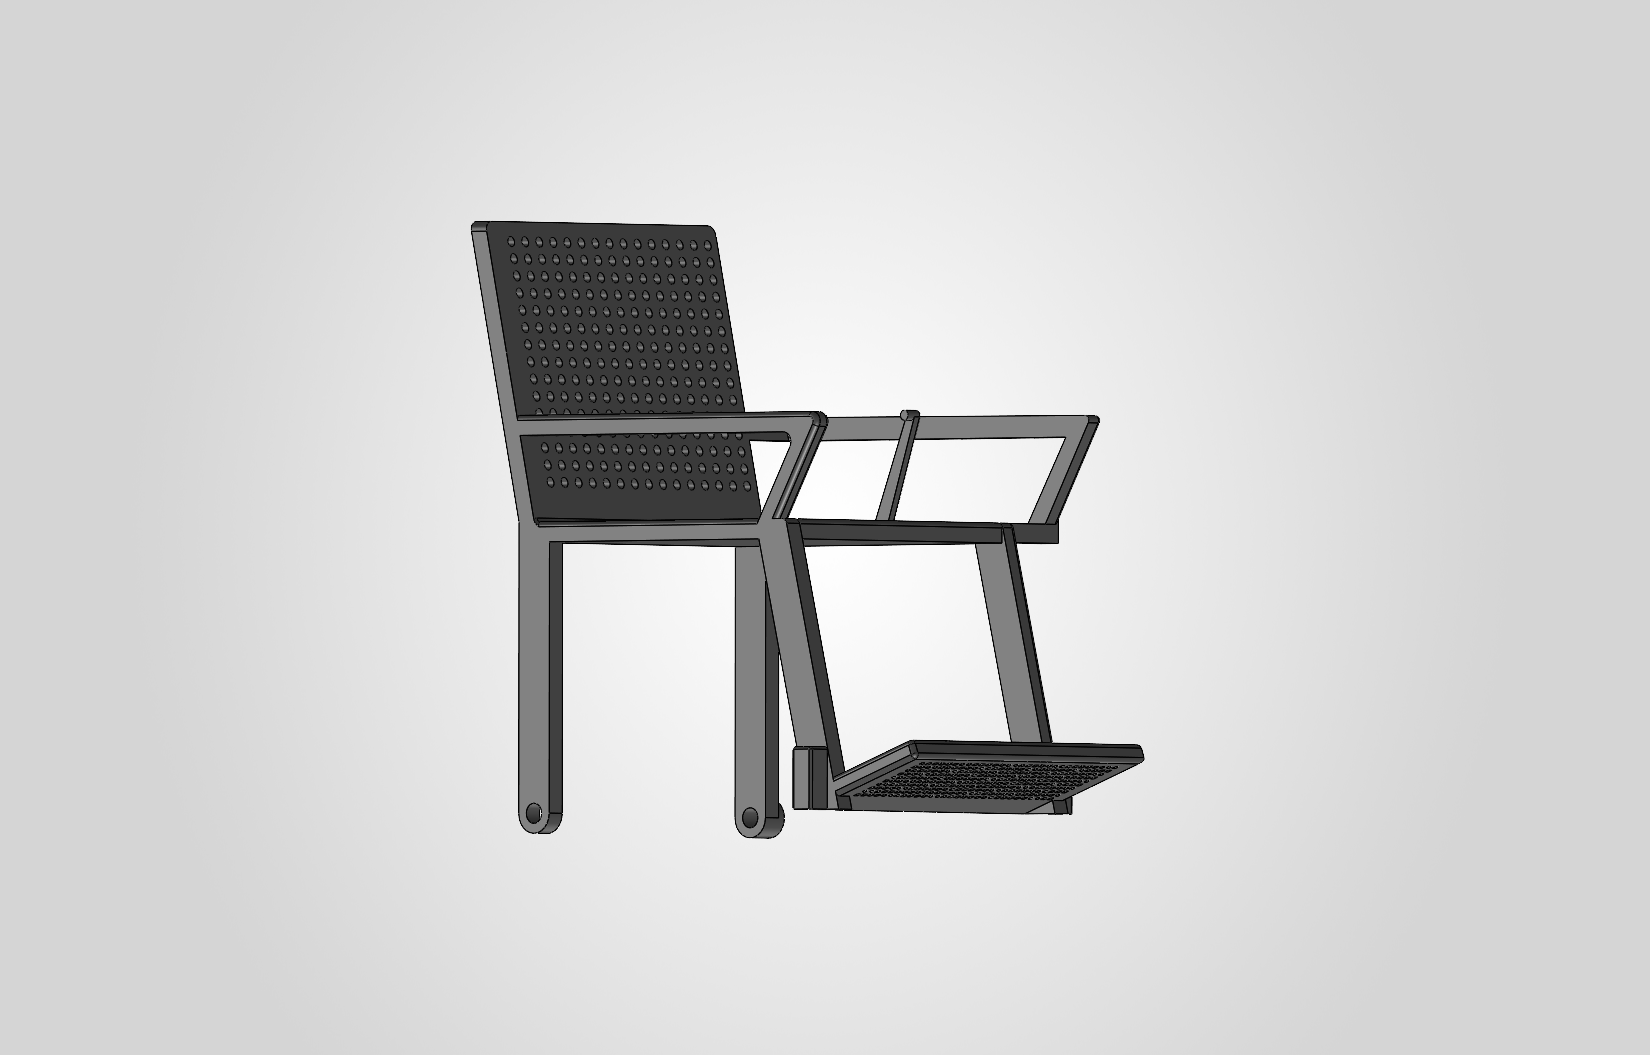
Chair
Supports the user and provides the main seating structure of the wheelchair
Material: Mild steel frame
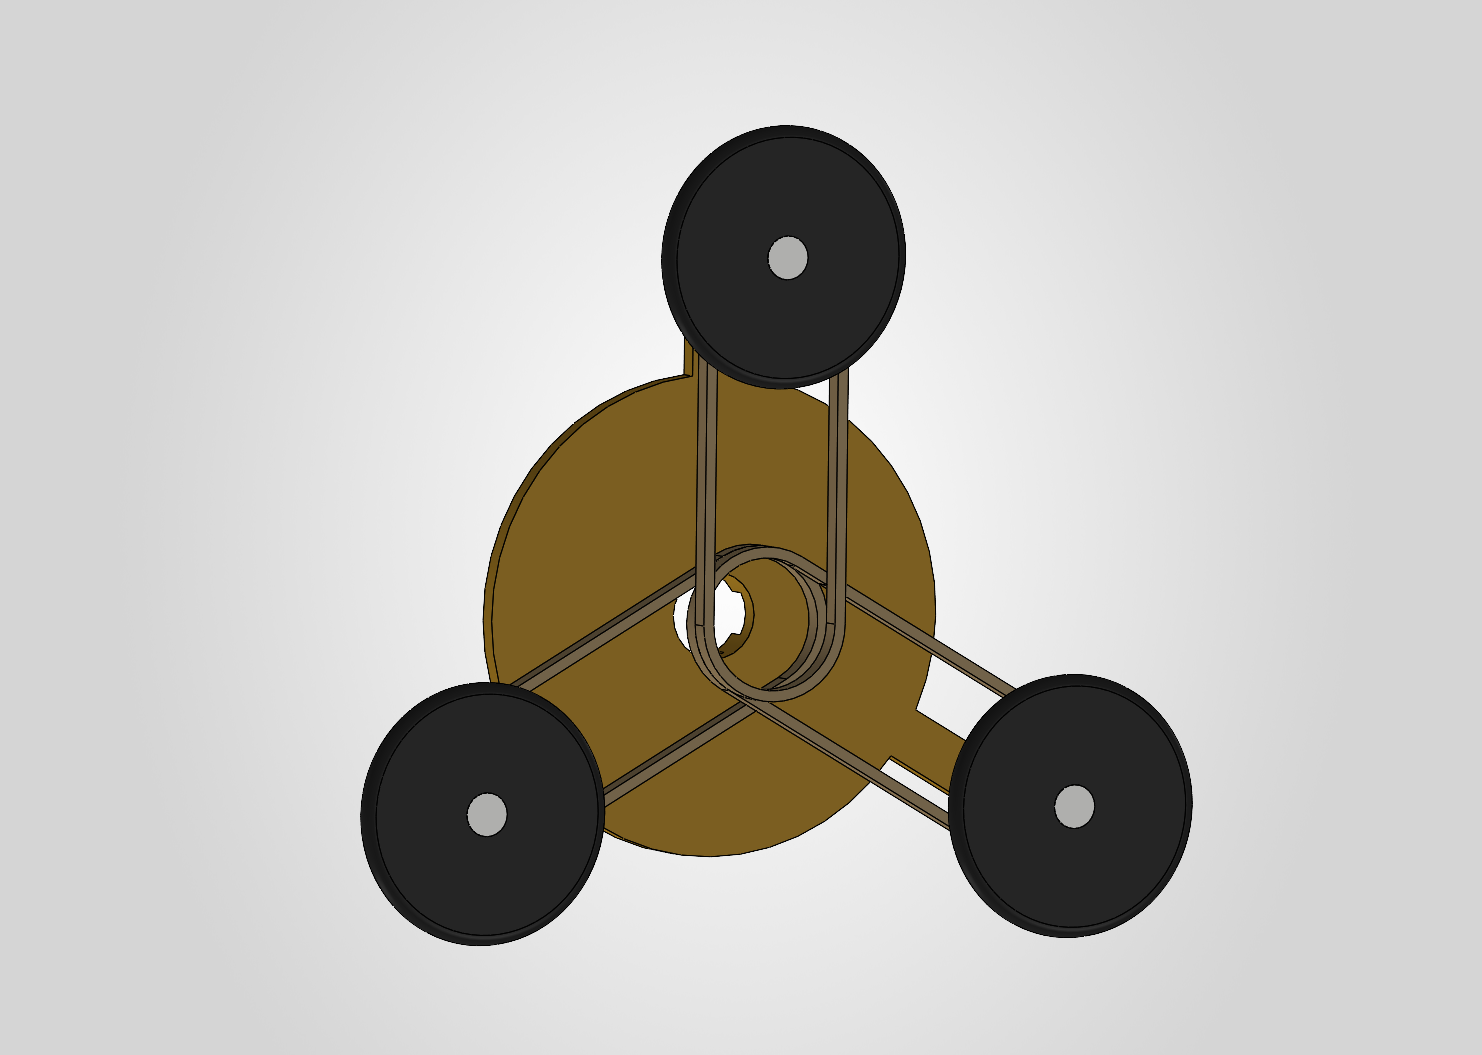
Wheel arrangement
Houses the three-wheel planetary arrangement used to negotiate stair steps
Material: Aluminium alloy for structural arms
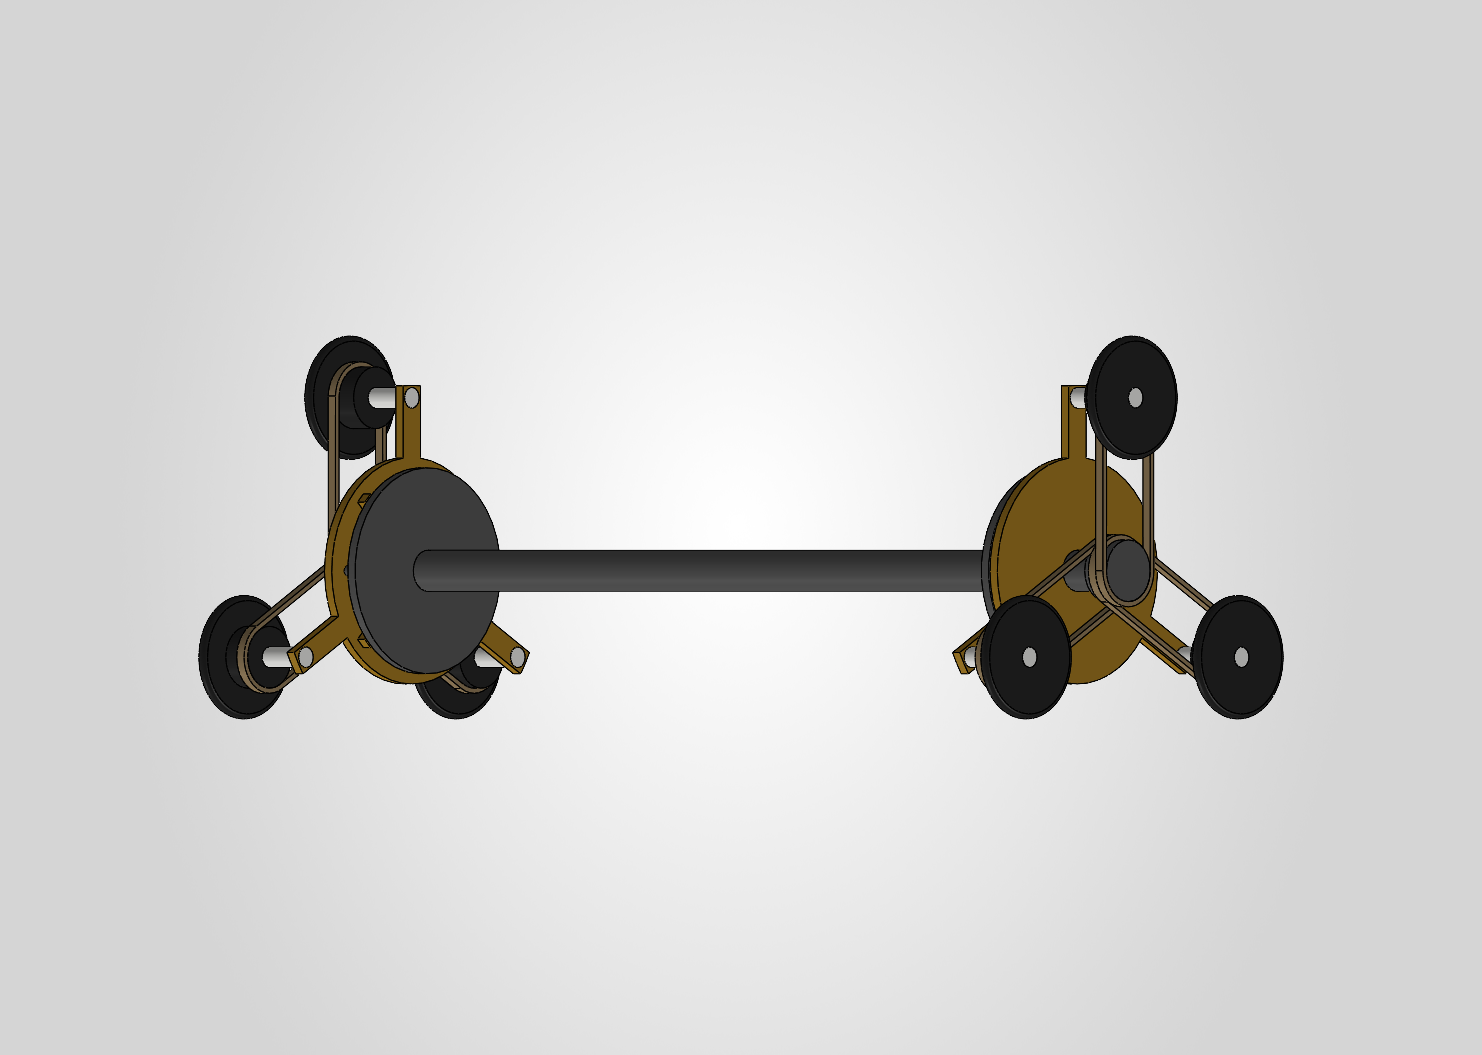
Back wheel structure
Supports the rear of the wheelchair and transmits motion during movement
Material: Aluminium alloy
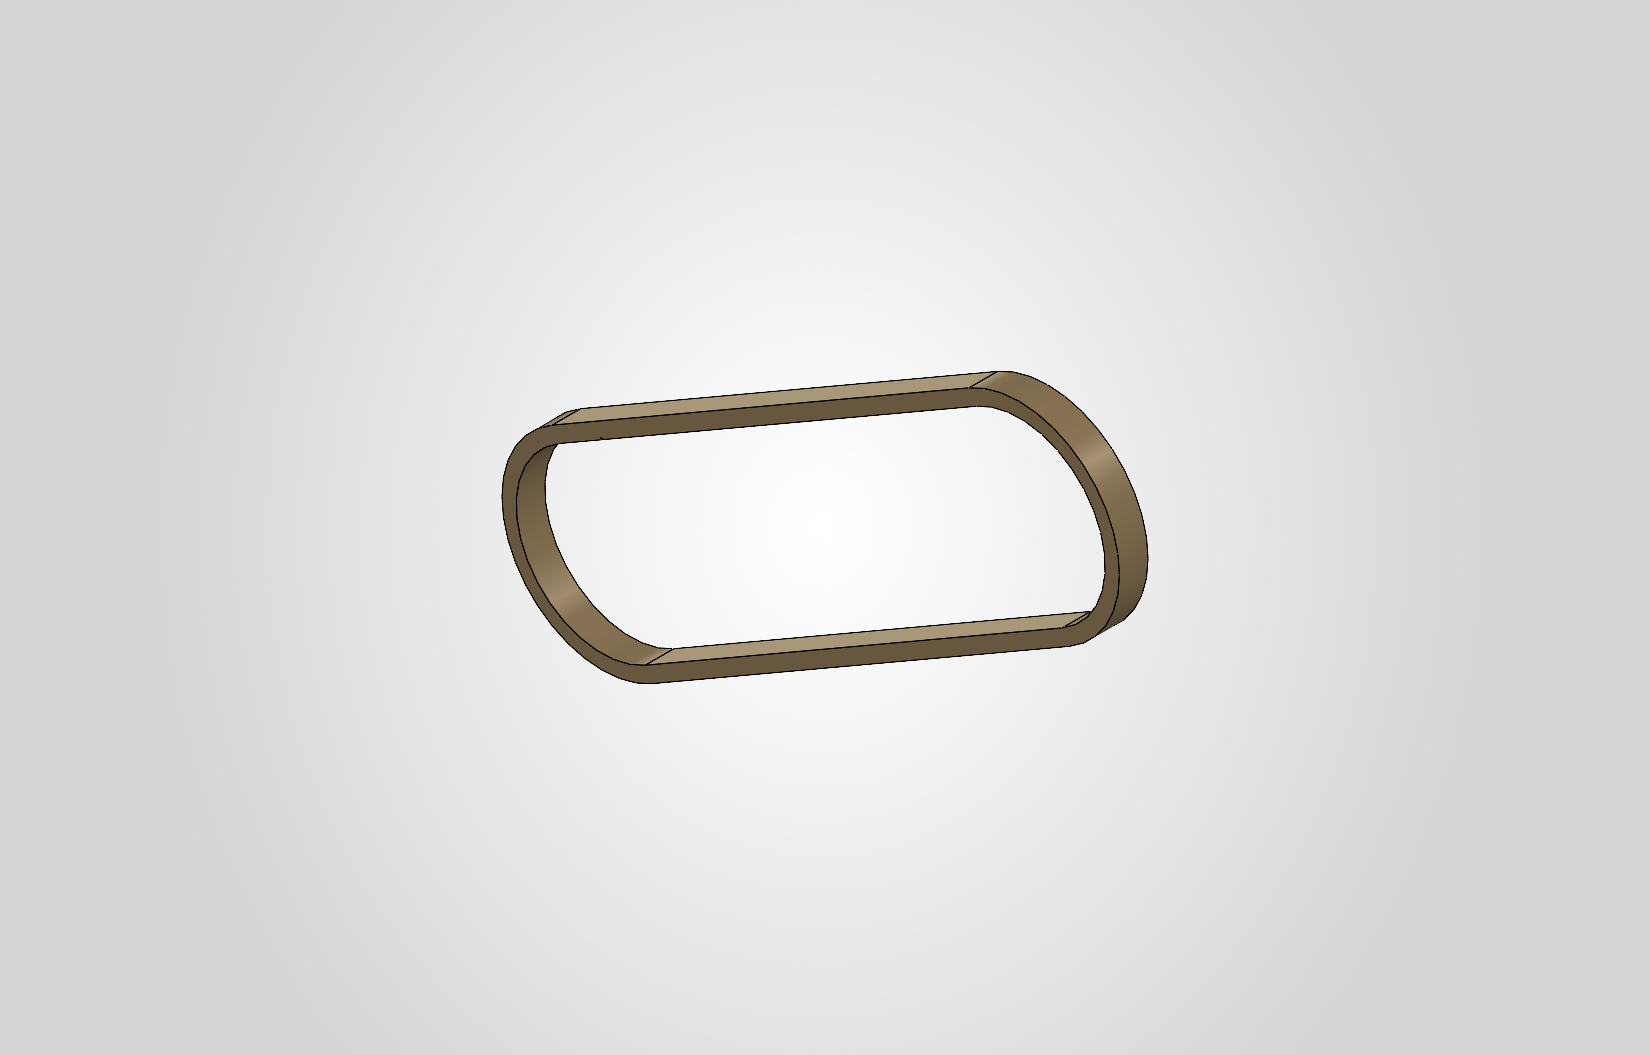
Planet Gear Belt
Transmits motion between the planetary gear mechanism and connected rotating components
Material: Reinforced rubber
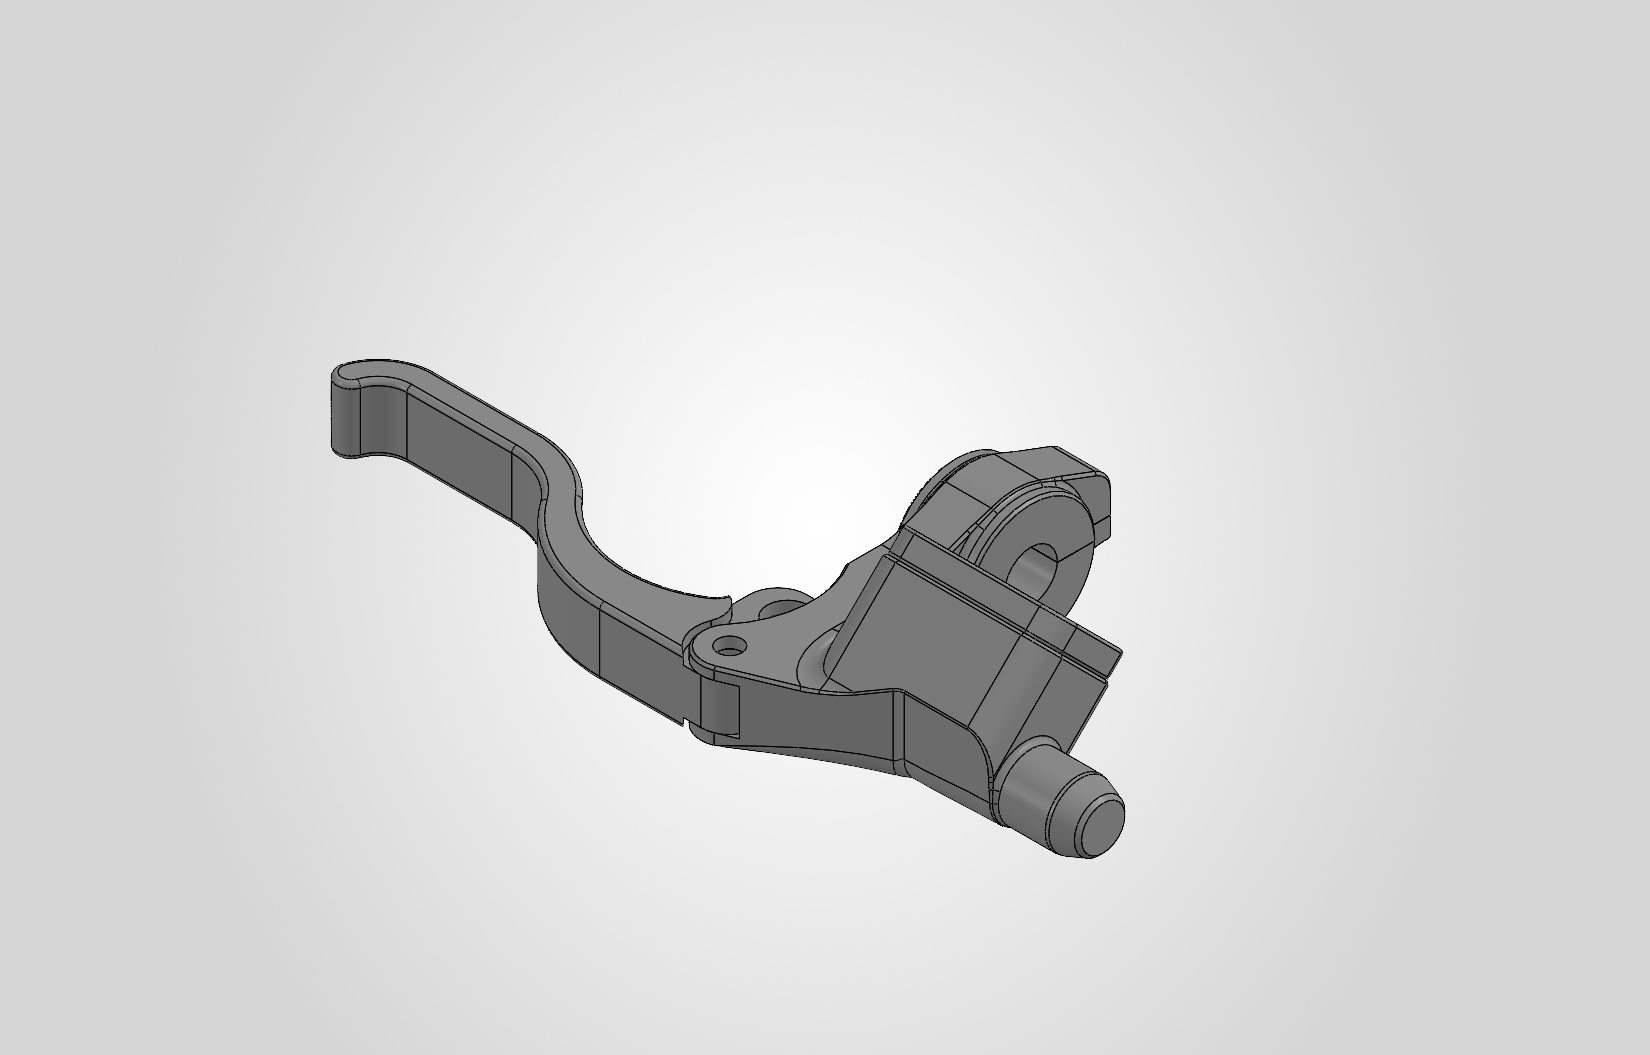
Brake Clutch
Engages or disengages the braking mechanism to control wheel movement
Material: Steel
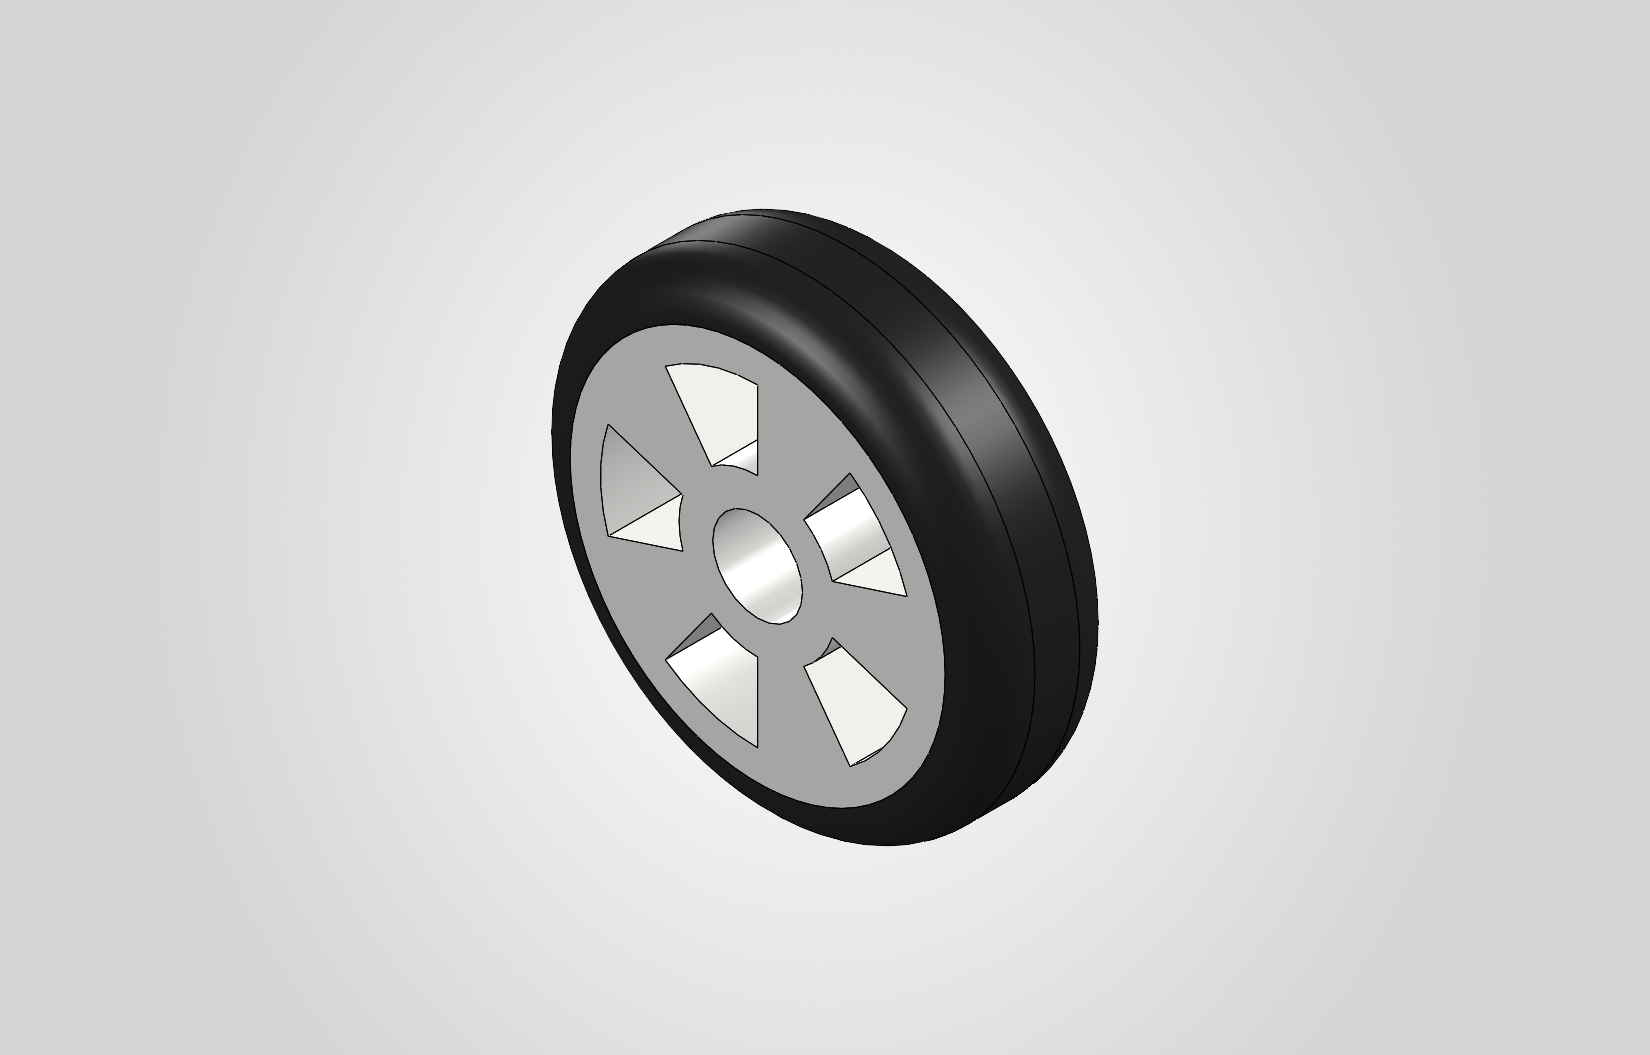
Front Wheel
Supports the front of the wheelchair and enables movement over flat surfaces
Material: Rubber tyre with a aluminium wheel hub
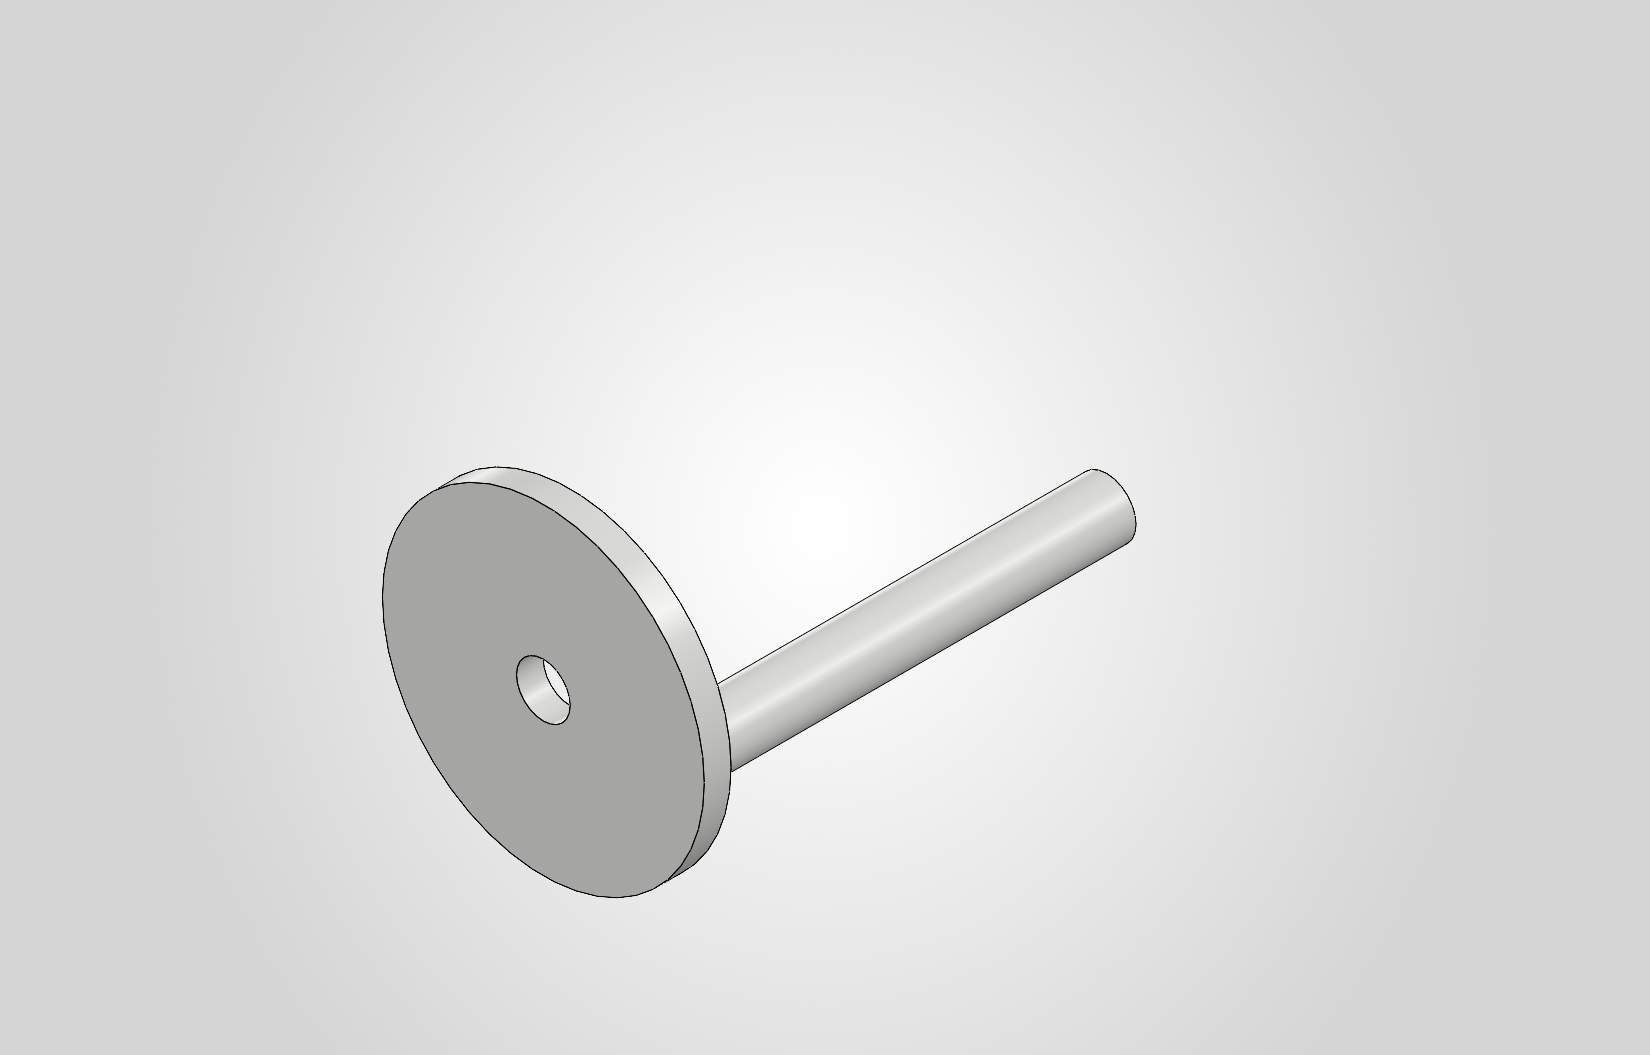
Hand Support
Provides a hand-operated interface for controlling
Material: Steel rod
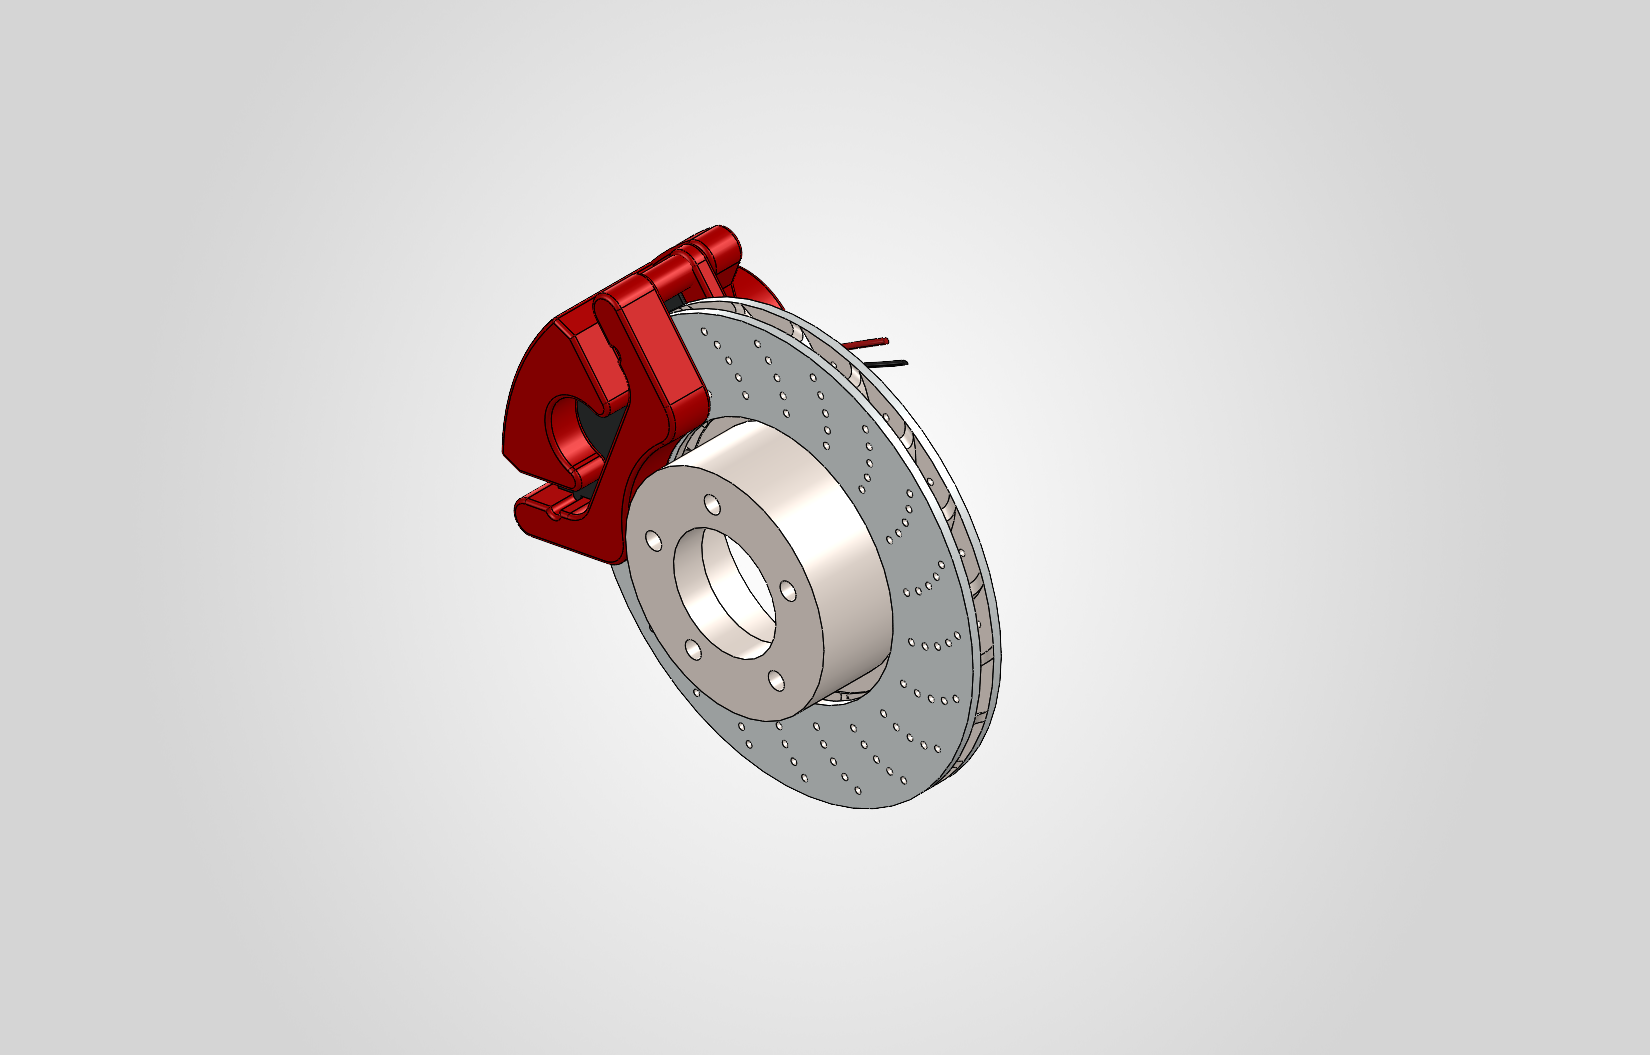
Disc Brake
Provides braking force to slow down or stop the wheelchair
Material: Stainless steel disc with a suitable friction pad material