Pick and Place
Robotic Arm
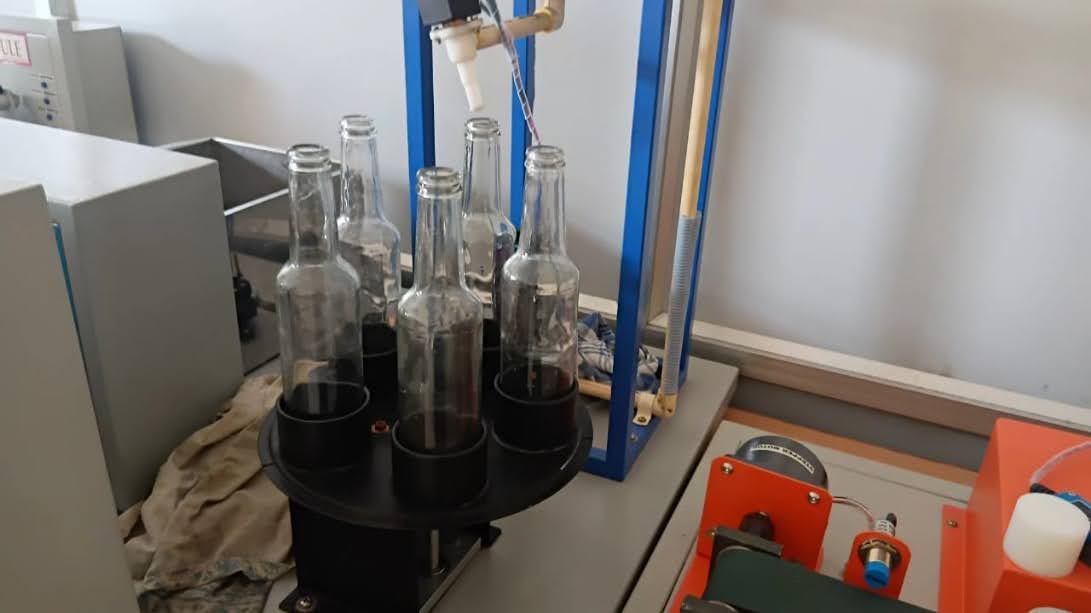
- The robotics lab had a rotary bottle-filling system, but transferring filled bottles into crates was a separate operation.
- The project explored automating this step using a robotic arm that could pick filled bottles from the rotary table and place them into a collection crate.
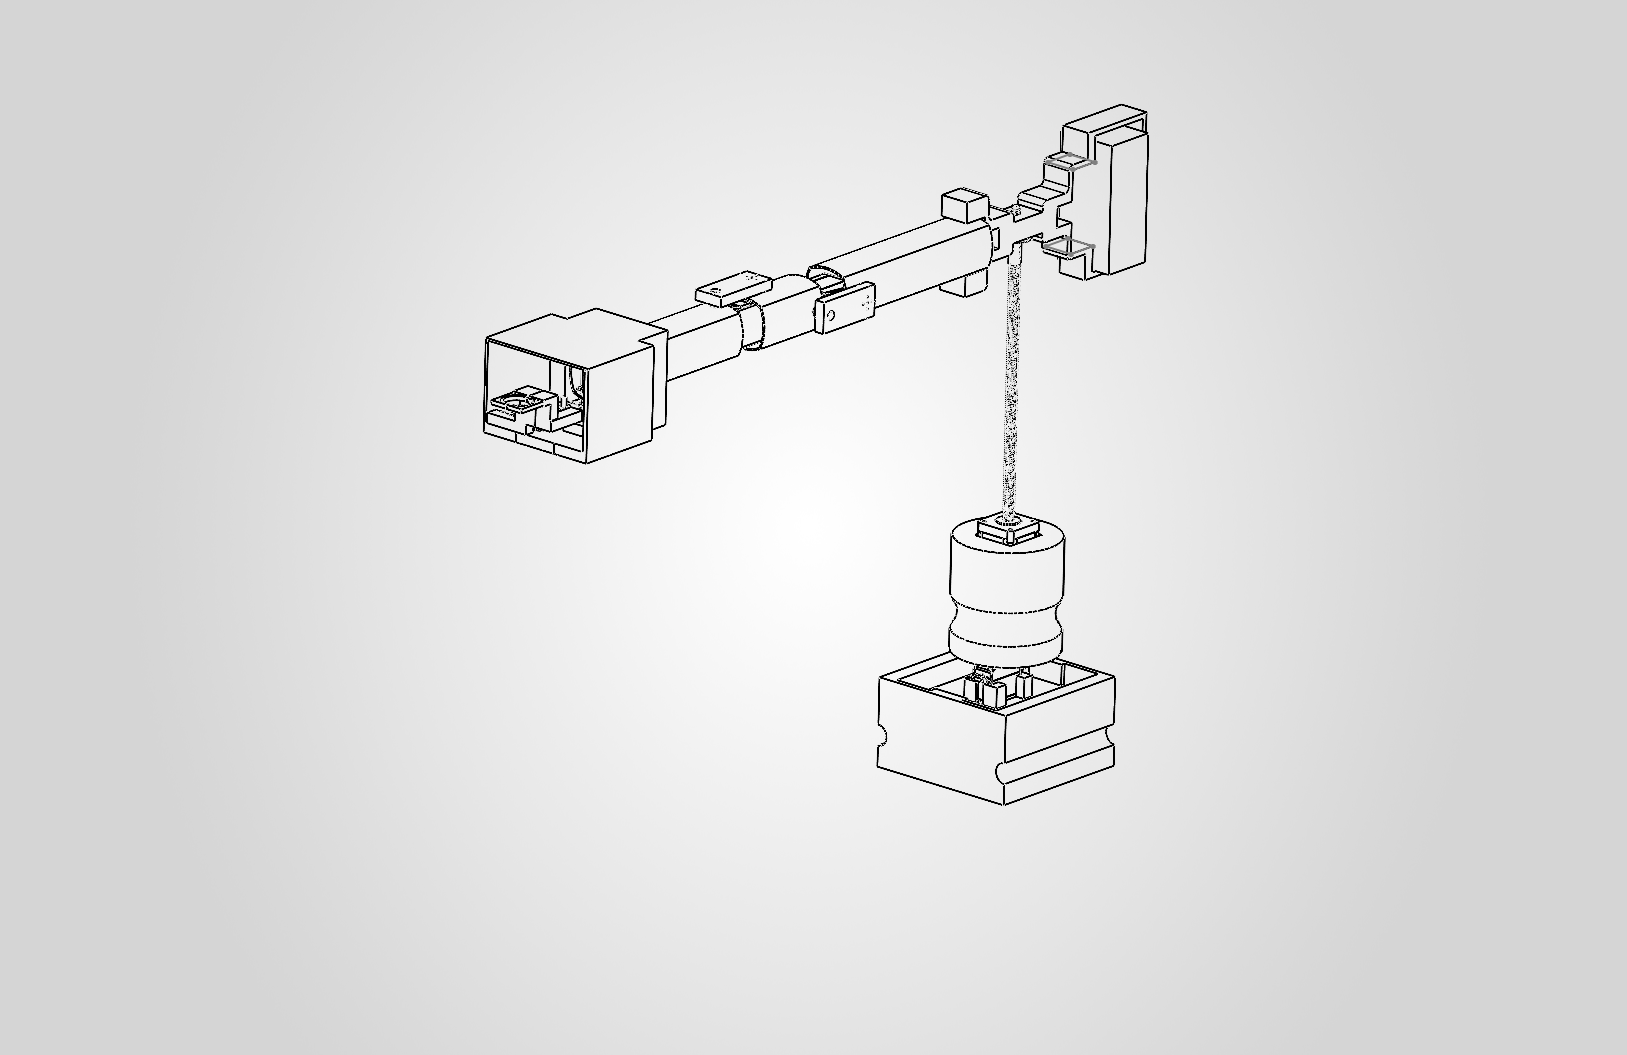
- Designed and developed a 4-DOF robotic arm to transfer filled bottles from a rotary table into a collection crate.
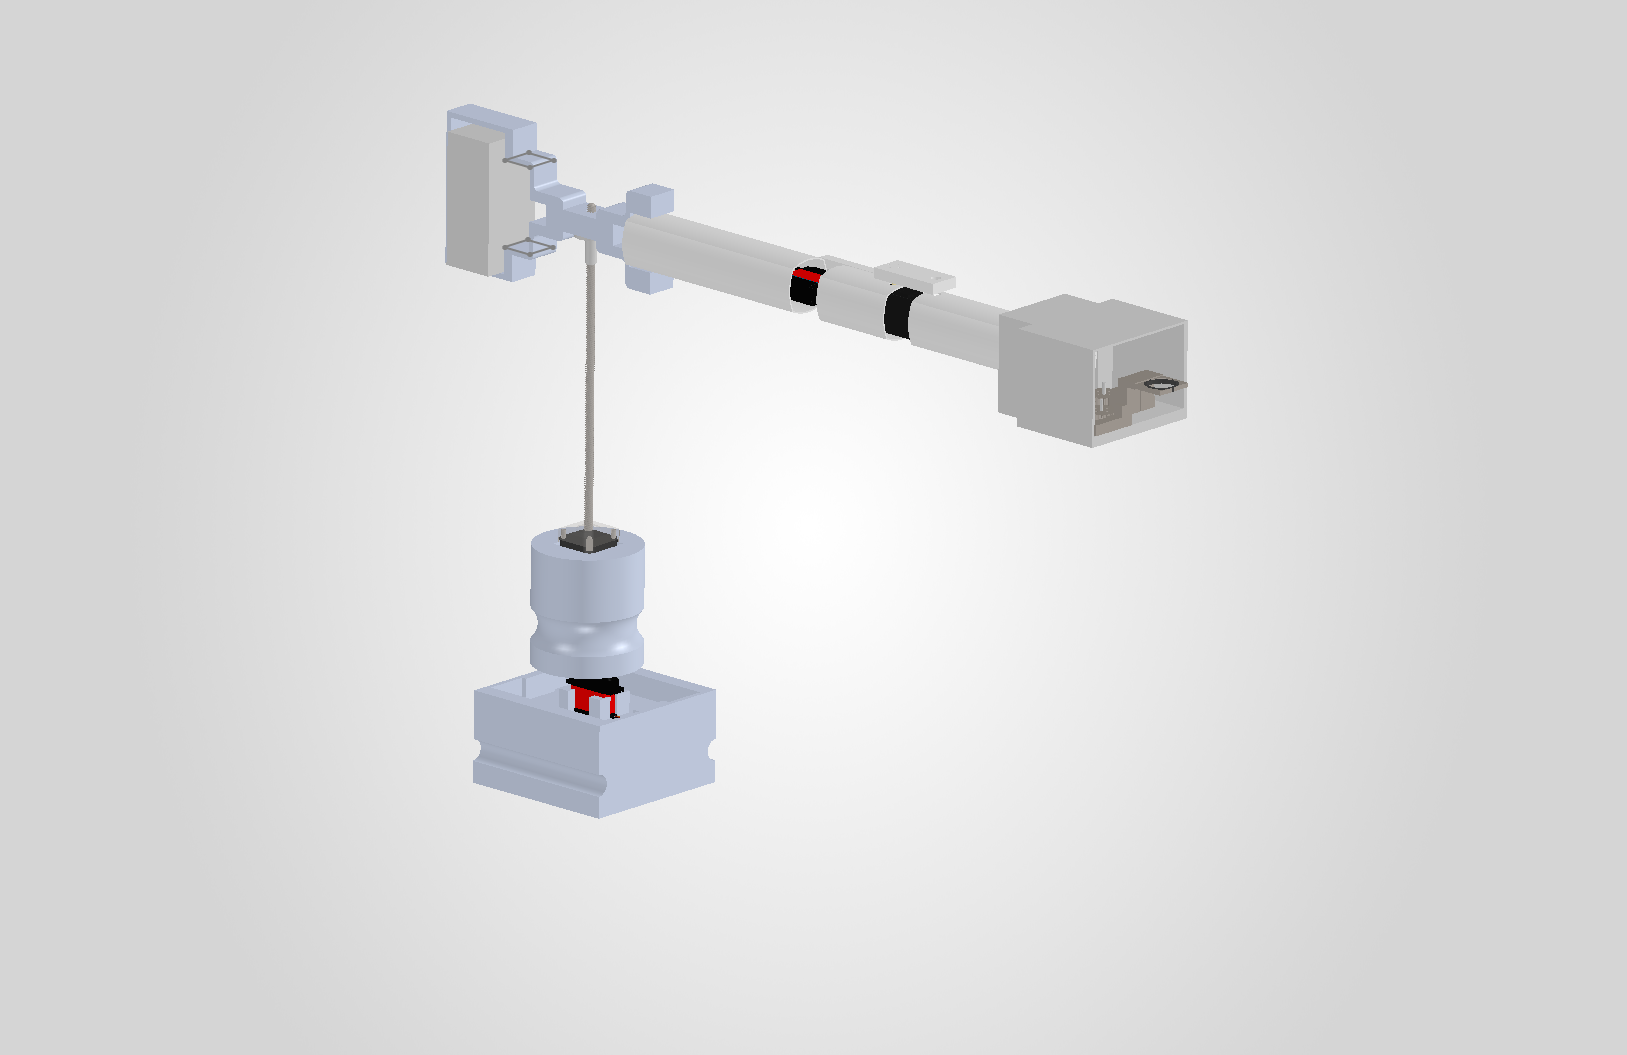
- Completed the mechanical design and assembly of the robotic arm.
- Moving towards prototype development, with physical testing and performance evaluation planned as the next stage.
Developed 3D CAD models and assembled the robotic arm, gripper, rotary table and collection crate into an integrated system.
Analysed the arm's kinematics, joint arrangement and torque requirements to plan bottle pick-and-place movements.
Defined the sensor placement and motor arrangement for coordinating bottle detection, picking and placement.
The Assembly
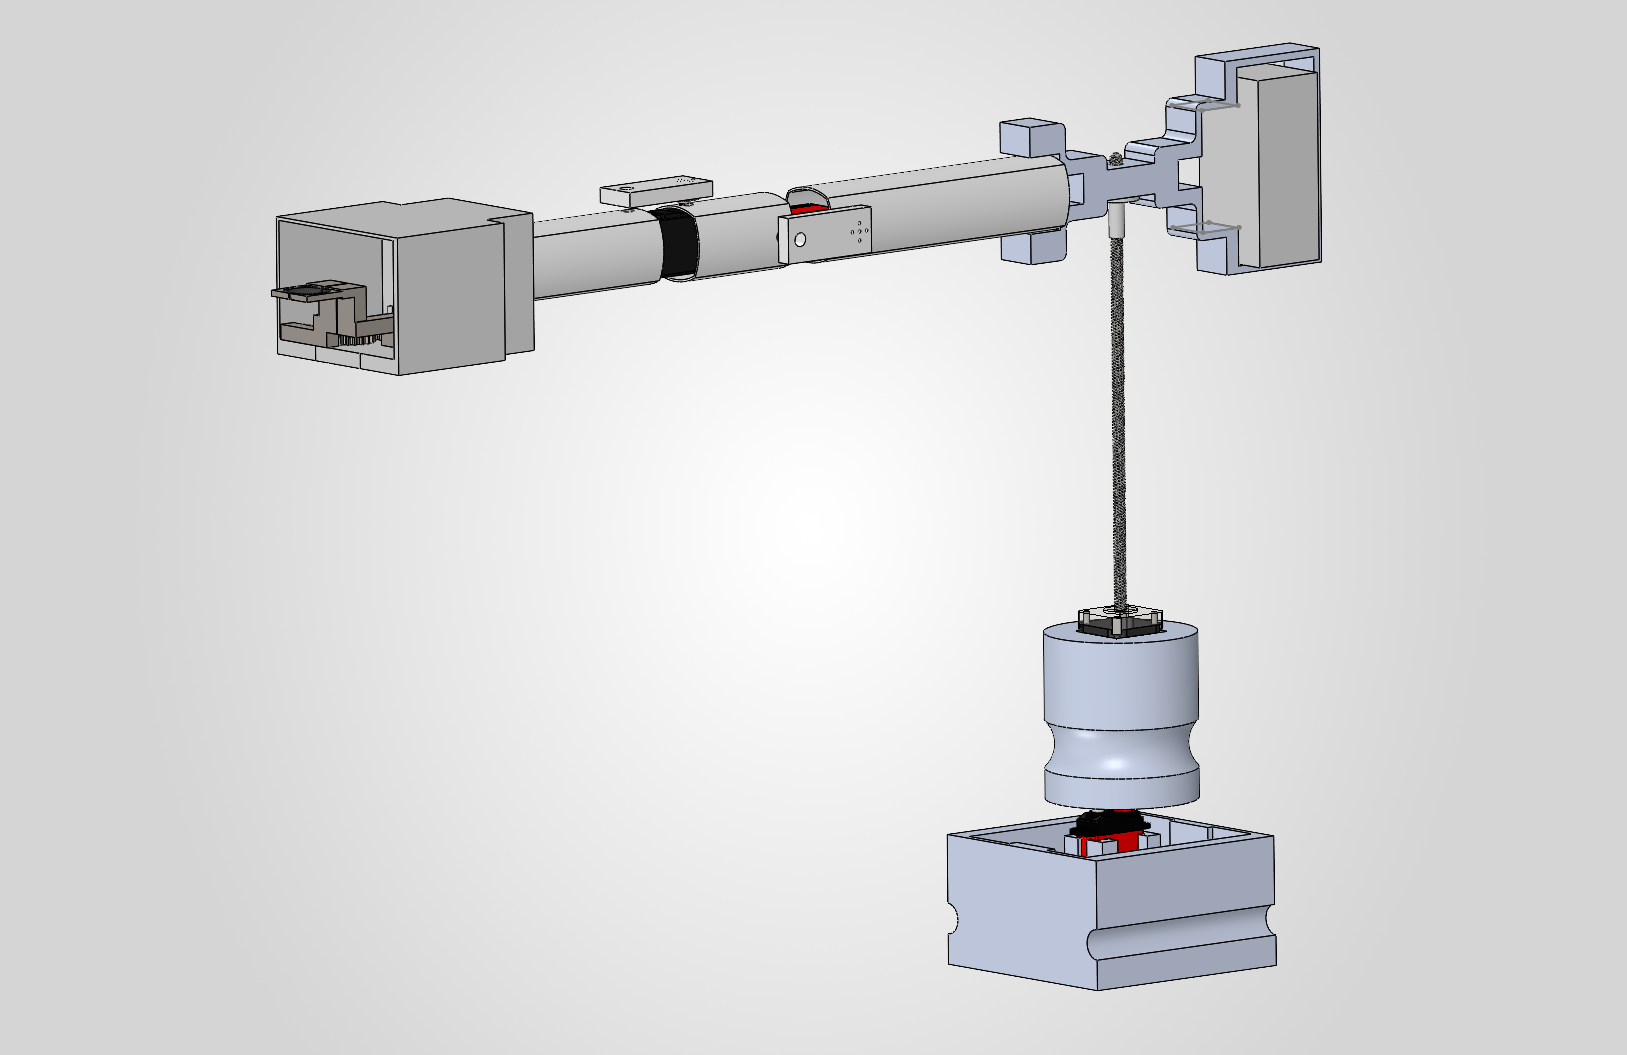
Component Breakdown
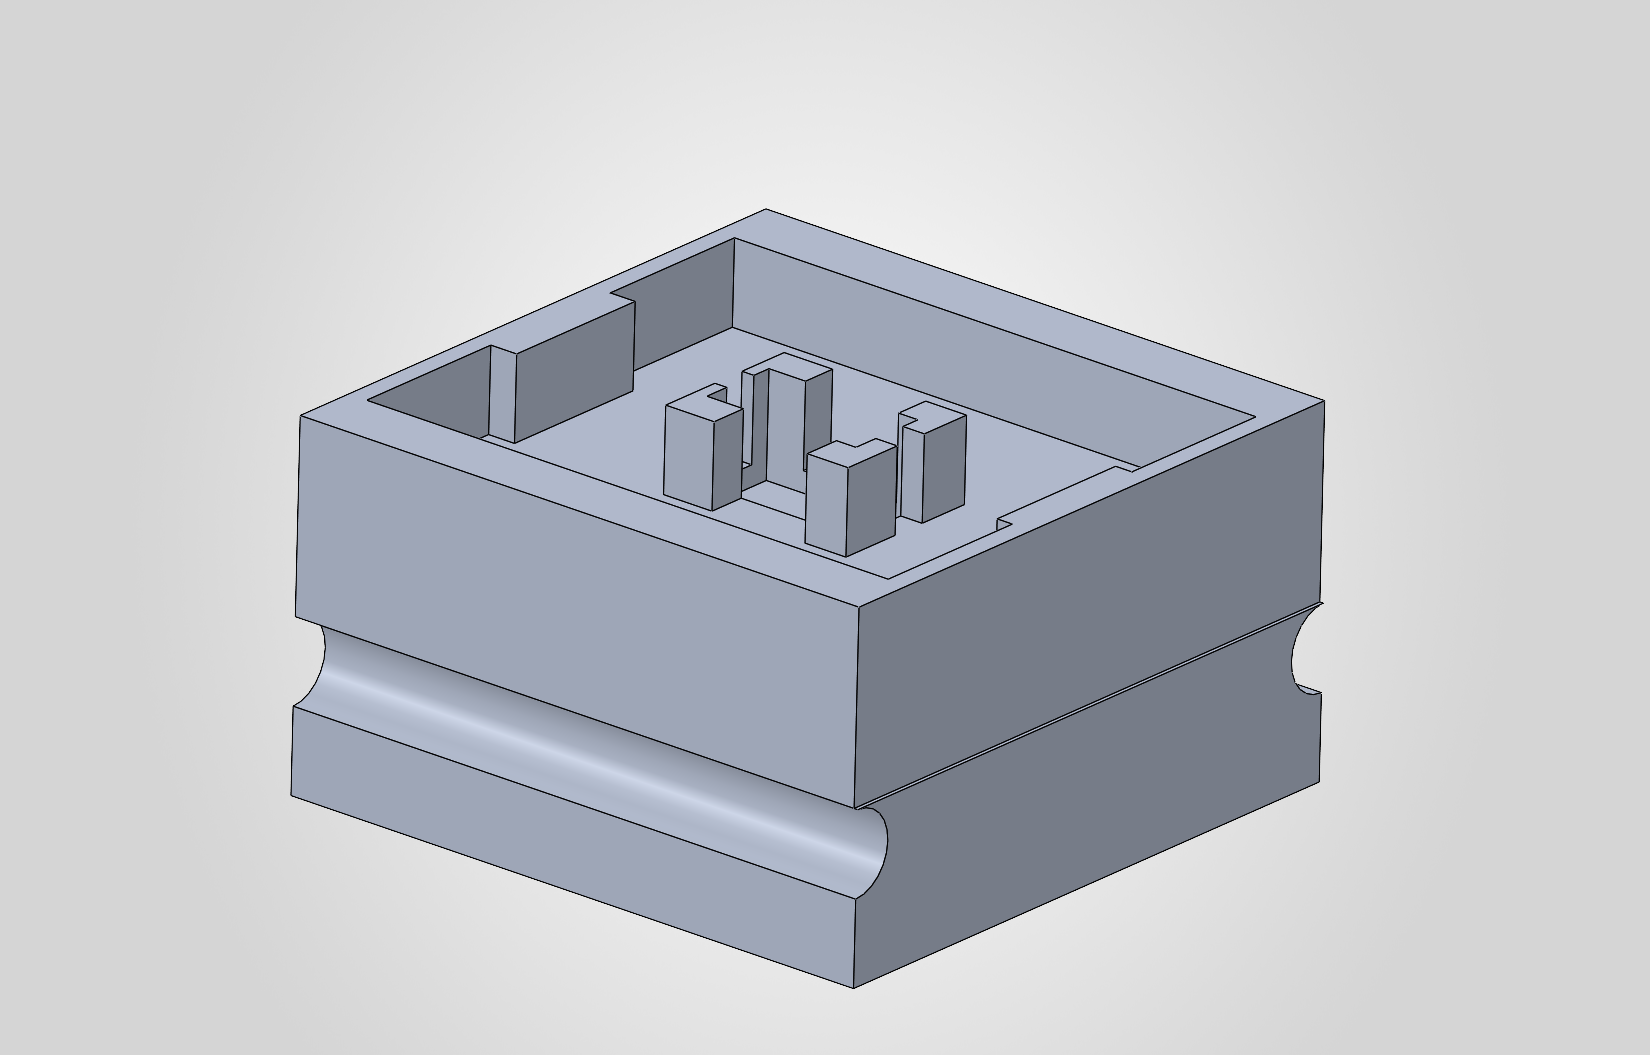
Ground Link
The main structure supporting the press assembly
Material: Aluminium alloy
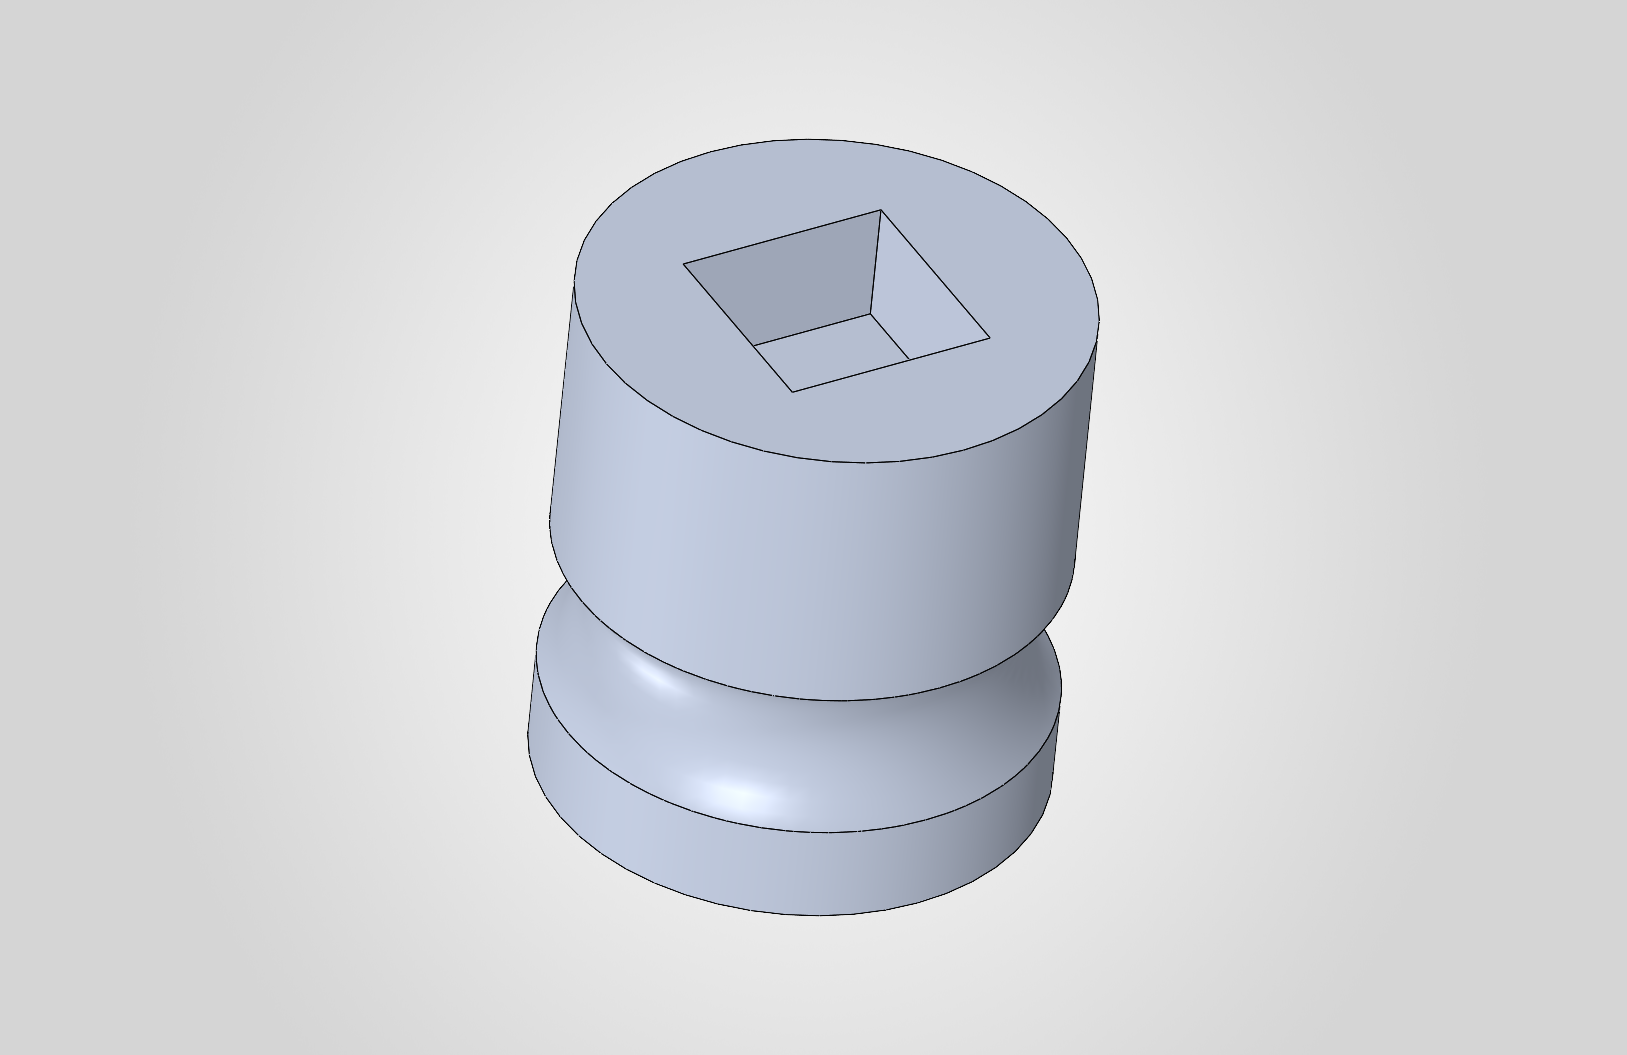
Base to Stepper
Connects the base structure to the stepper motor and helps transmit rotational motion to the arm.
Material: Aluminium alloy
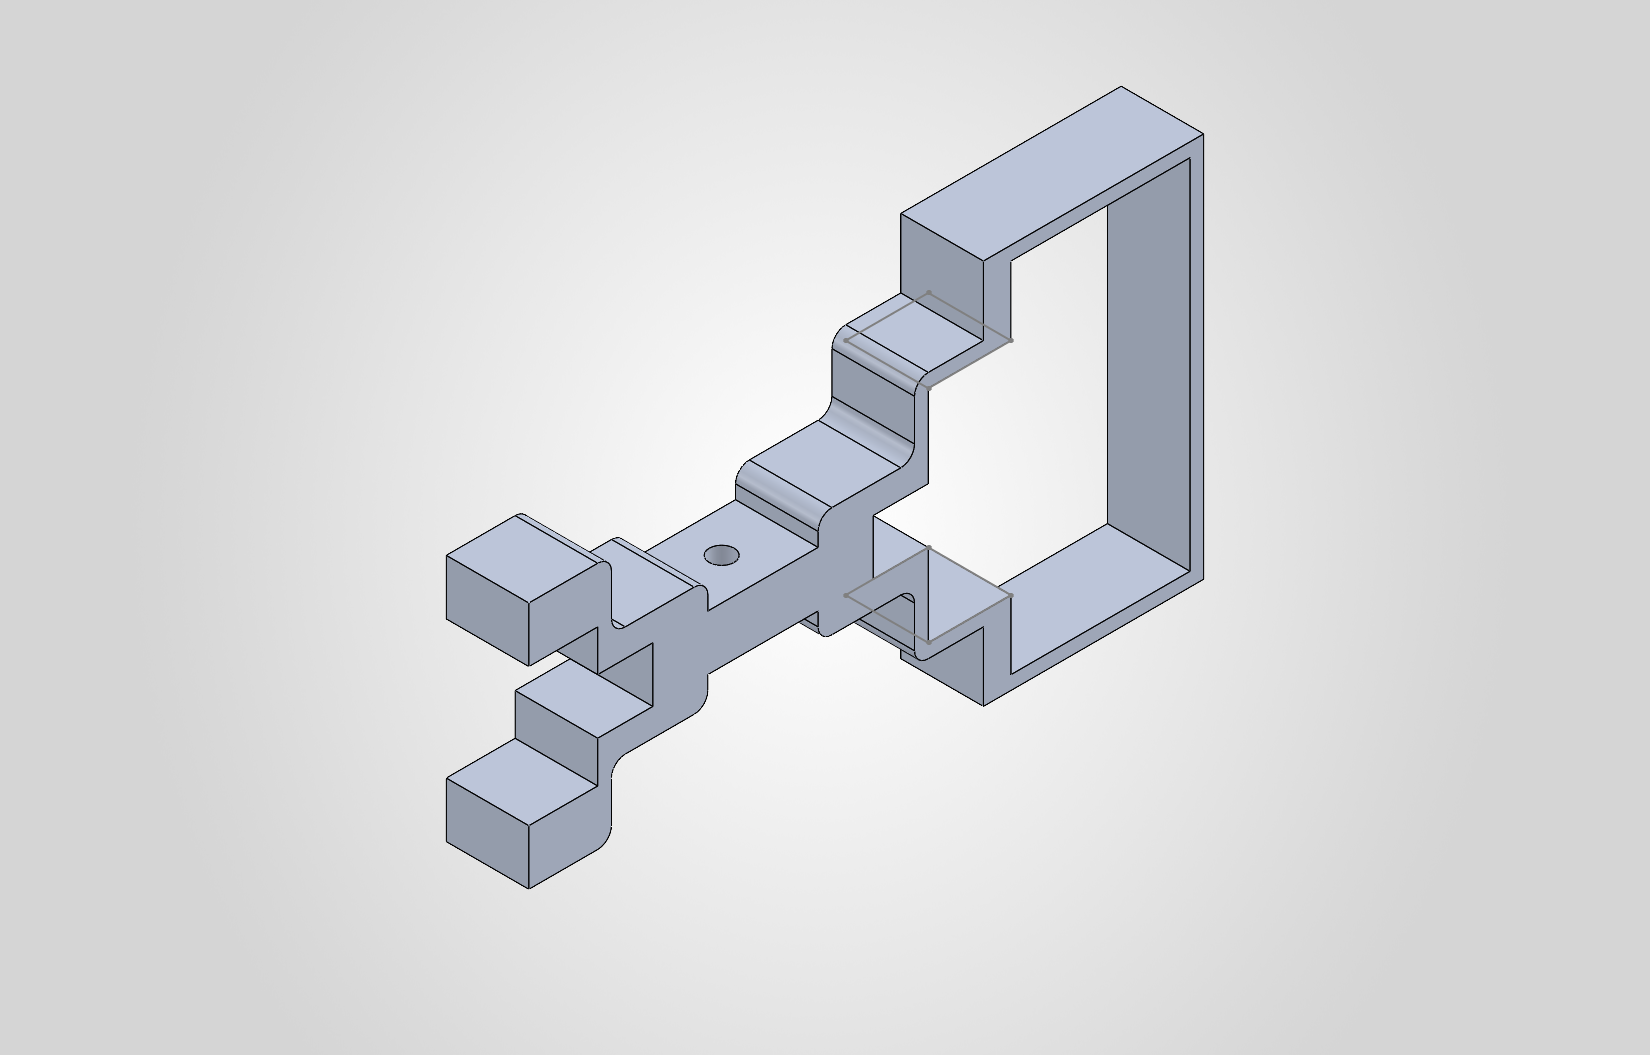
Connector
Connects adjacent structural components and maintains their alignment during arm movement.
Material: Aluminium alloy
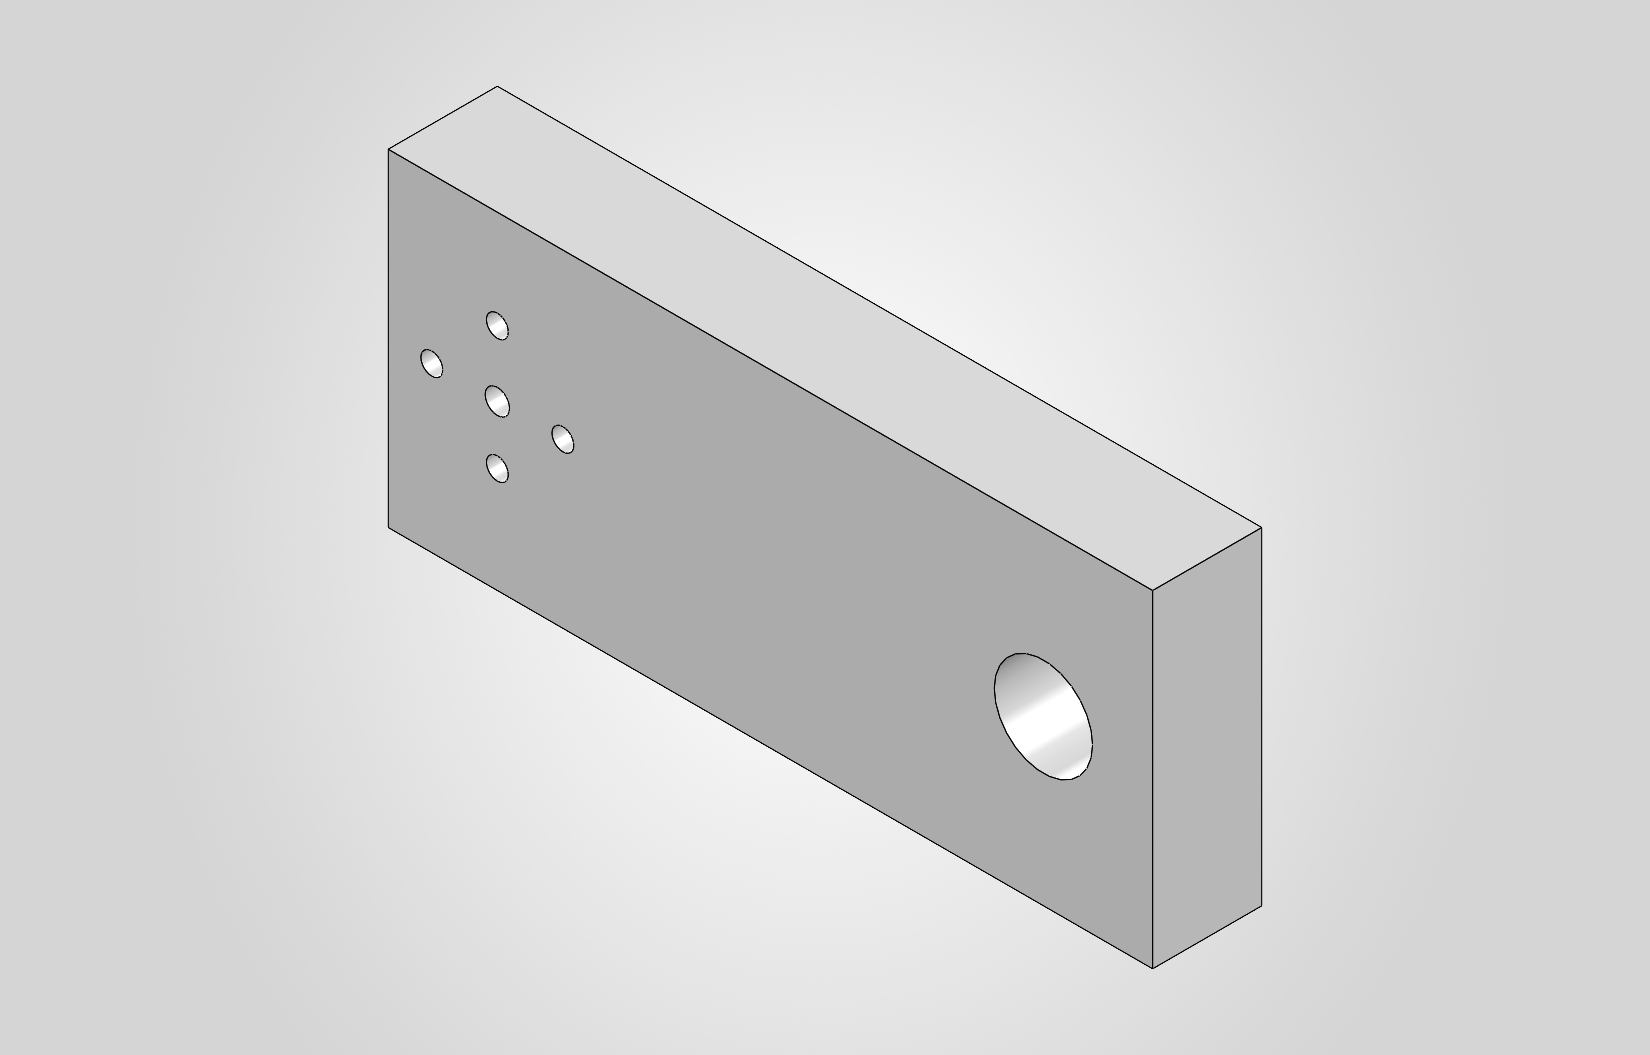
Bridge
Provides a rigid mounting interface between connected arm components and helps transfer mechanical loads.
Material: Aluminium alloy
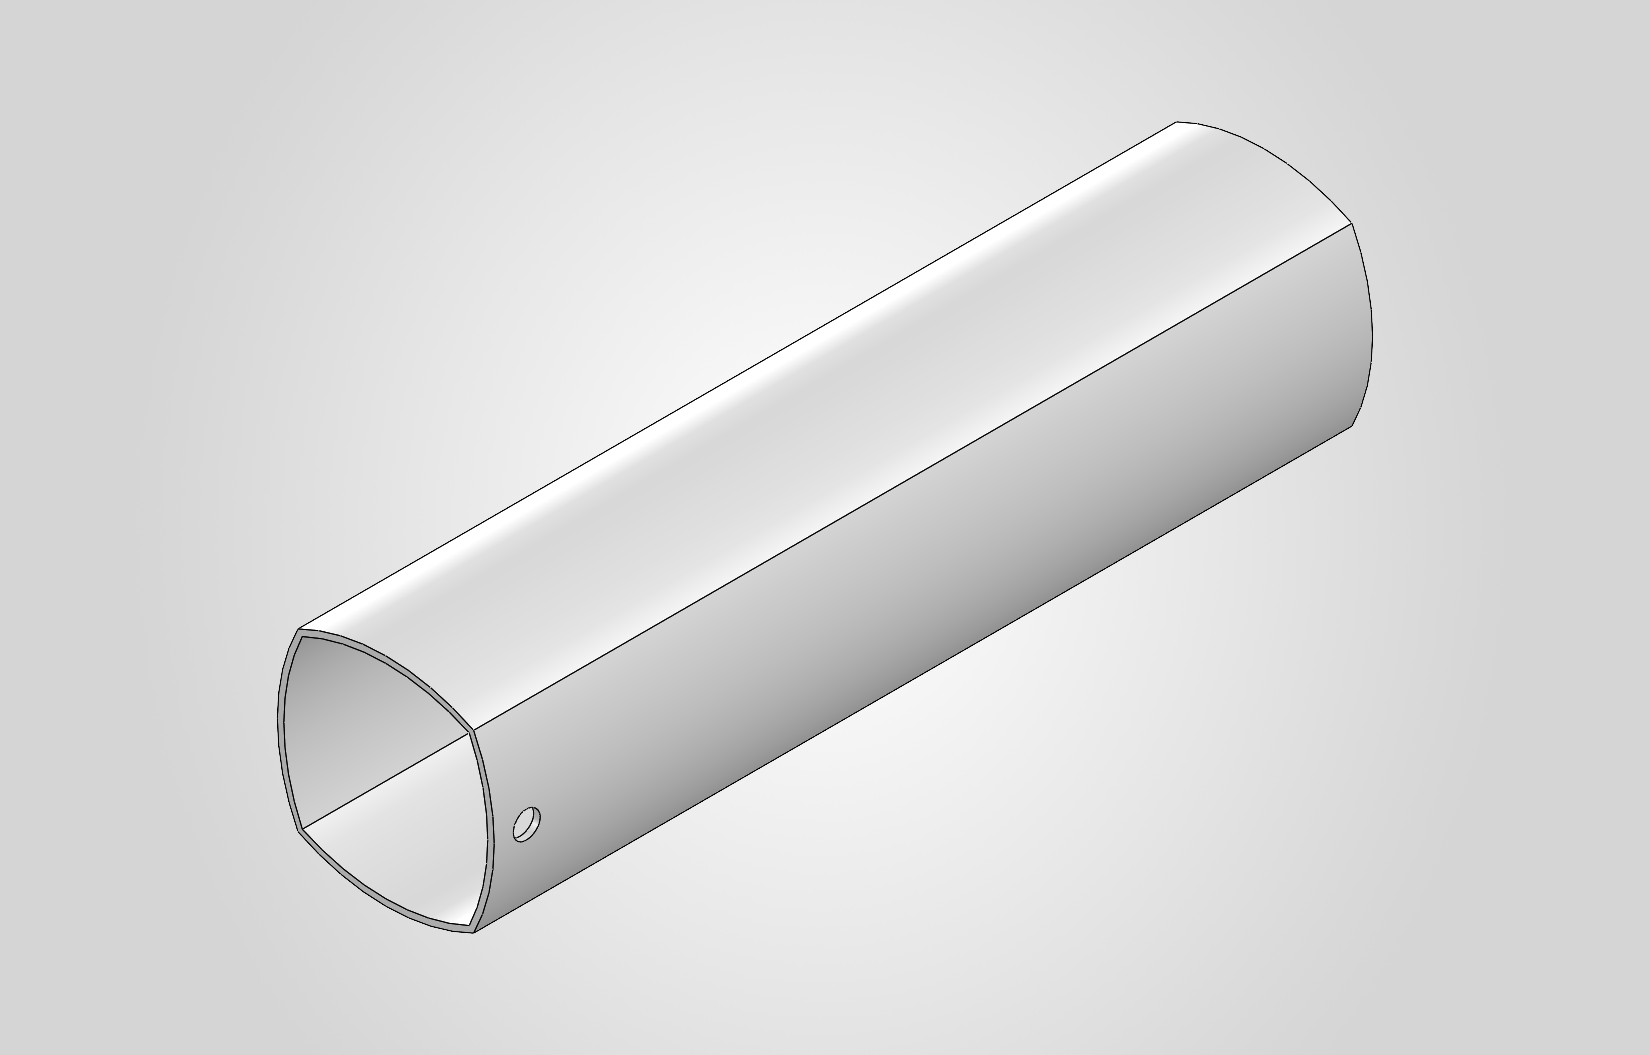
Upper Arm
Forms the main structural link between joints and extending the arm's reach
Material: Aluminum alloy
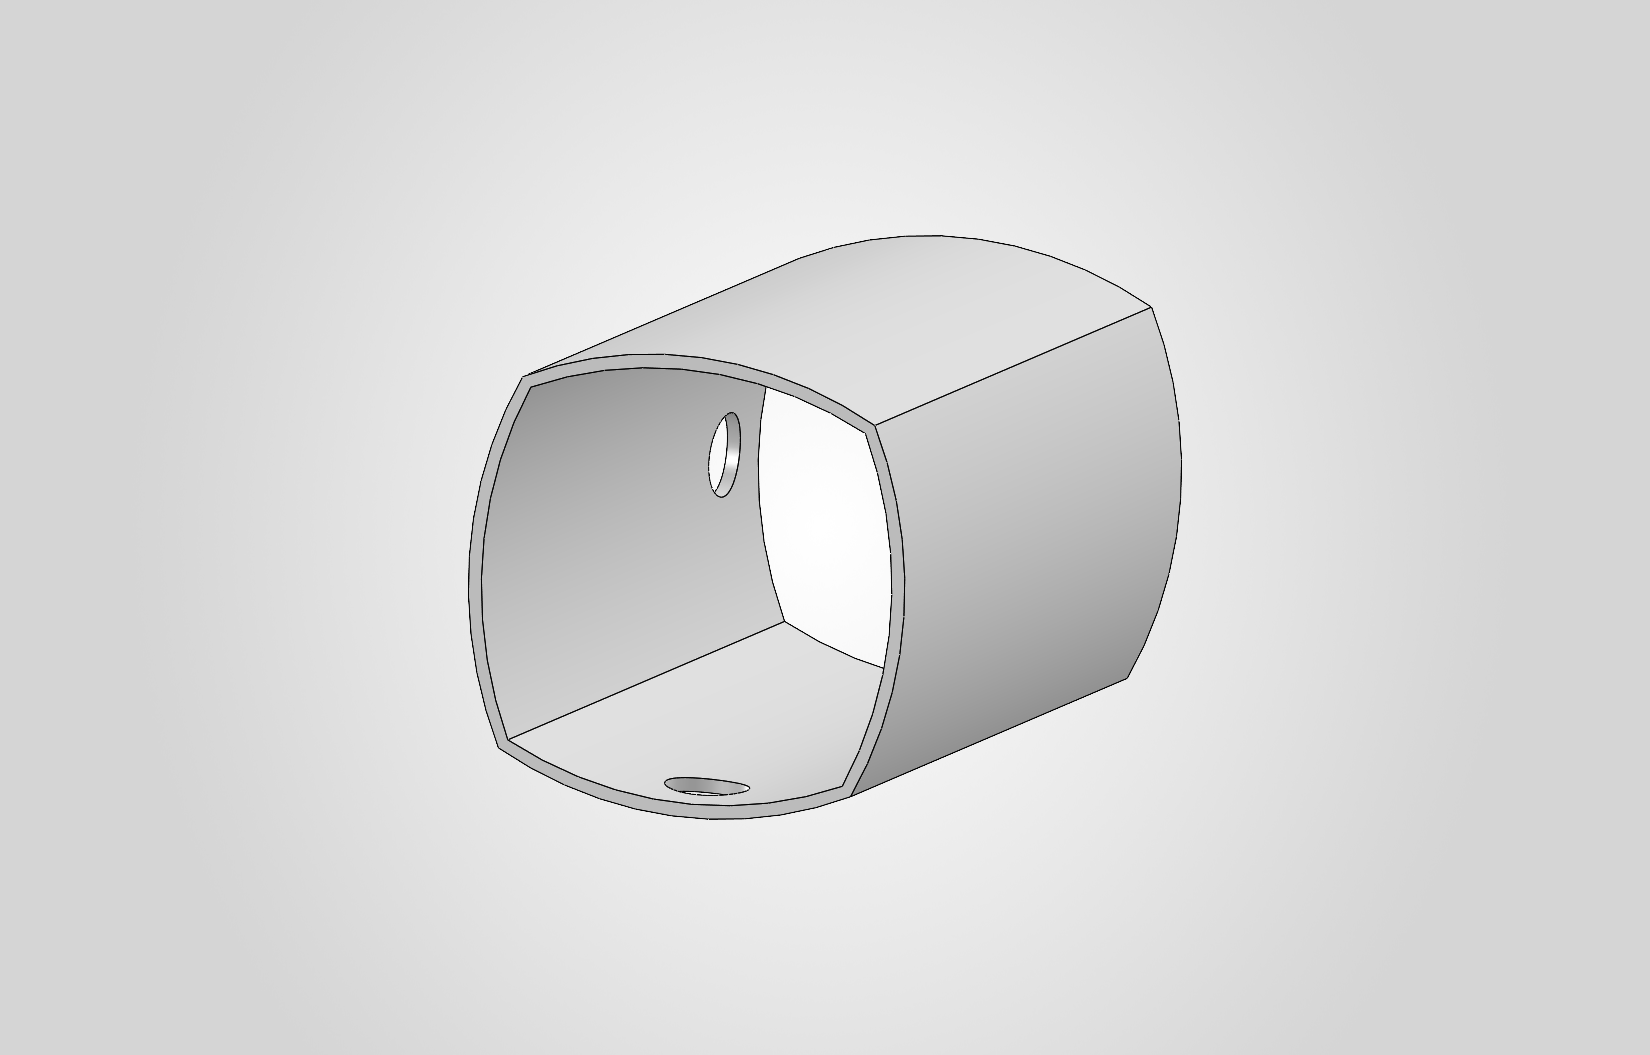
Mid Arm
Connects the upper and forearm sections, enabling the arm to position the gripper over the target.
Material: Aluminium alloy
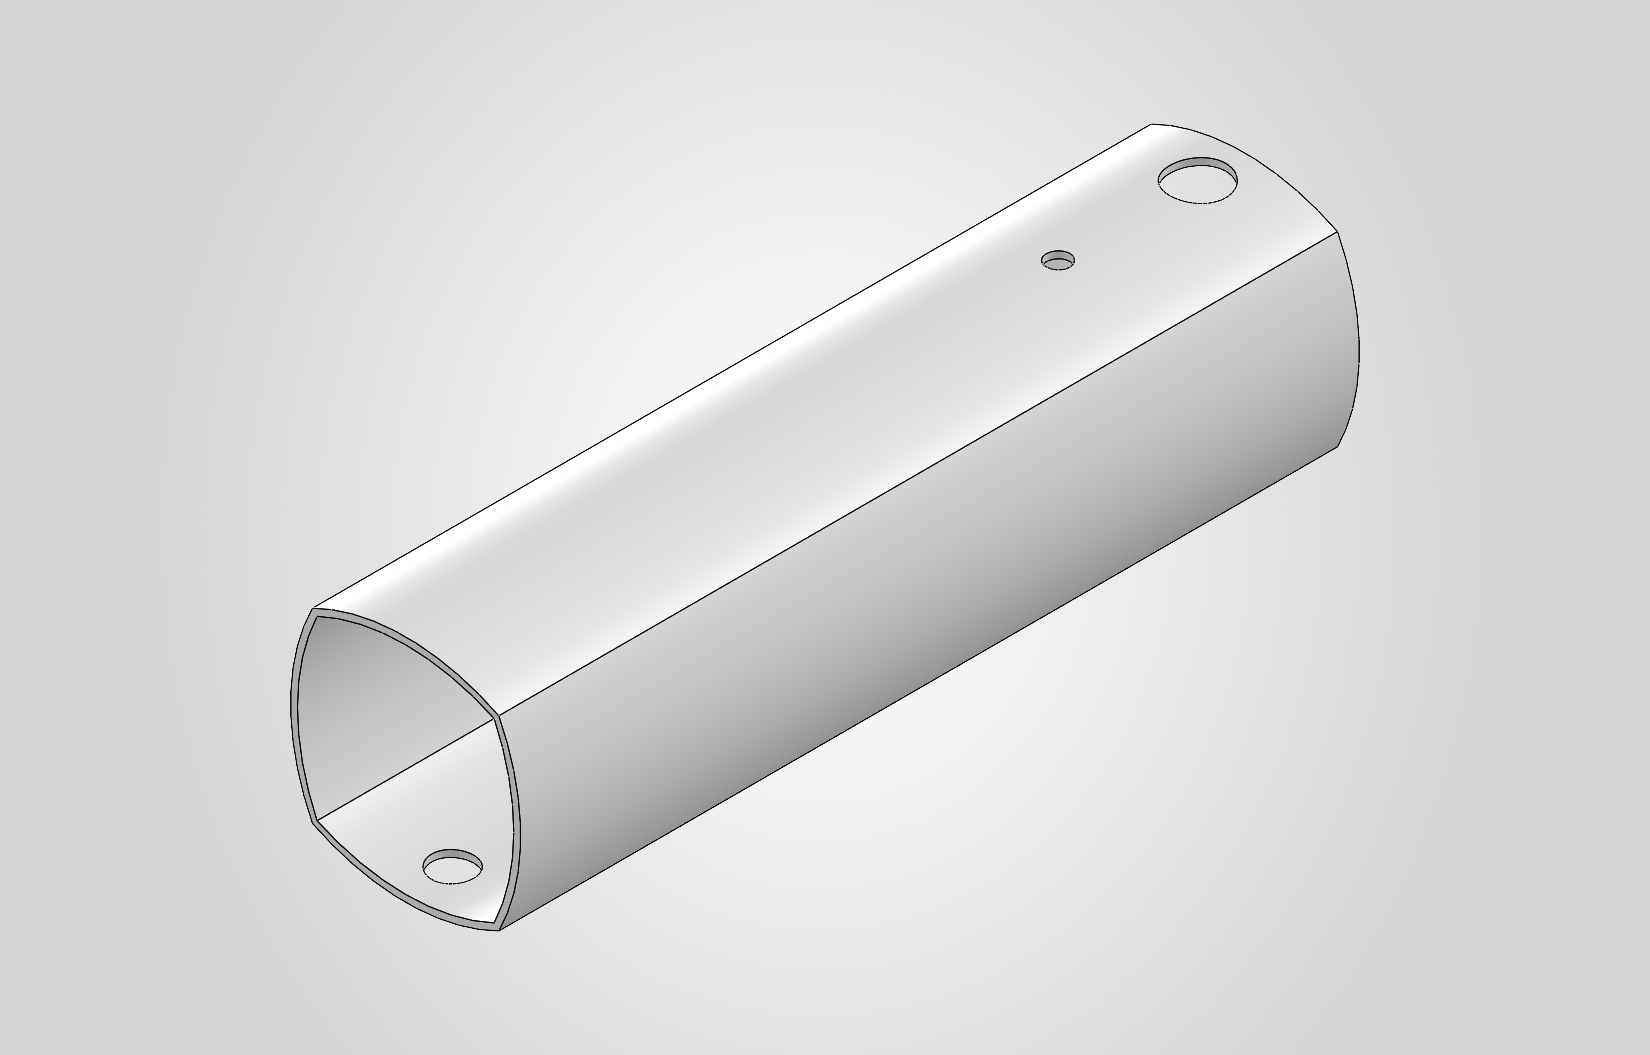
Fore Arm
Connects the mid-arm section to the gripper assembly and positions it near the bottle.
Material: Aluminium alloy
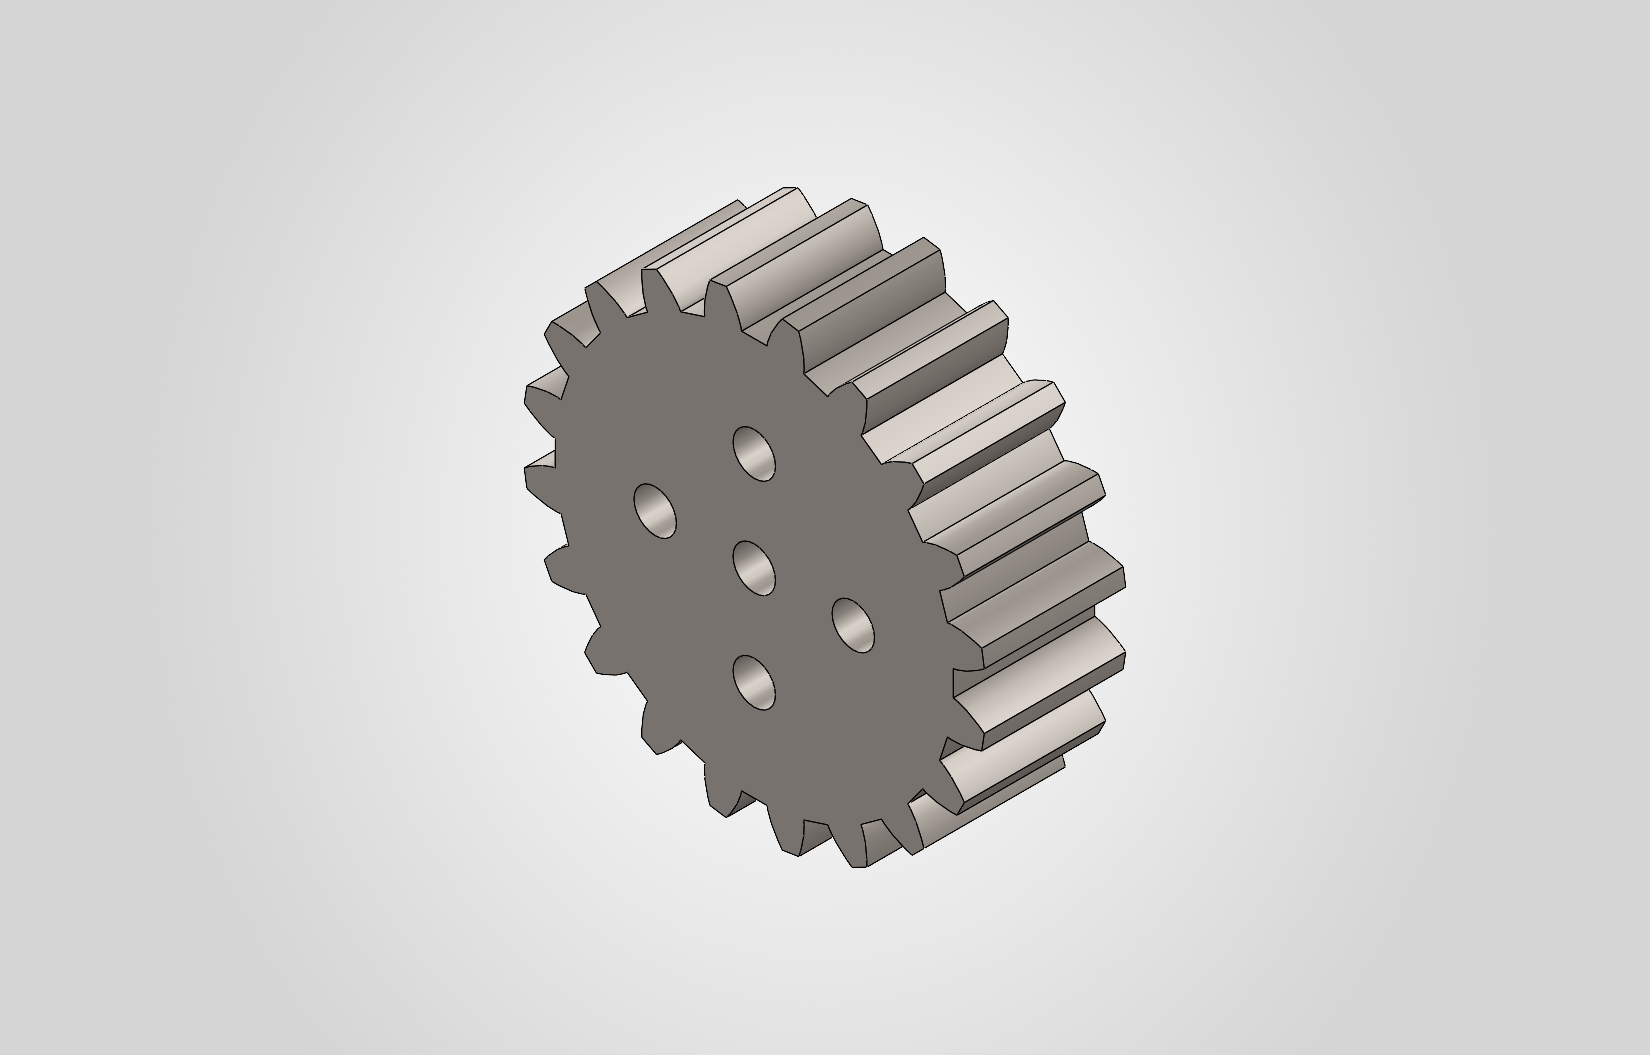
Gear
Transfers rotational motion between meshing gears to drive the arm's joint mechanism.
Material: Steel
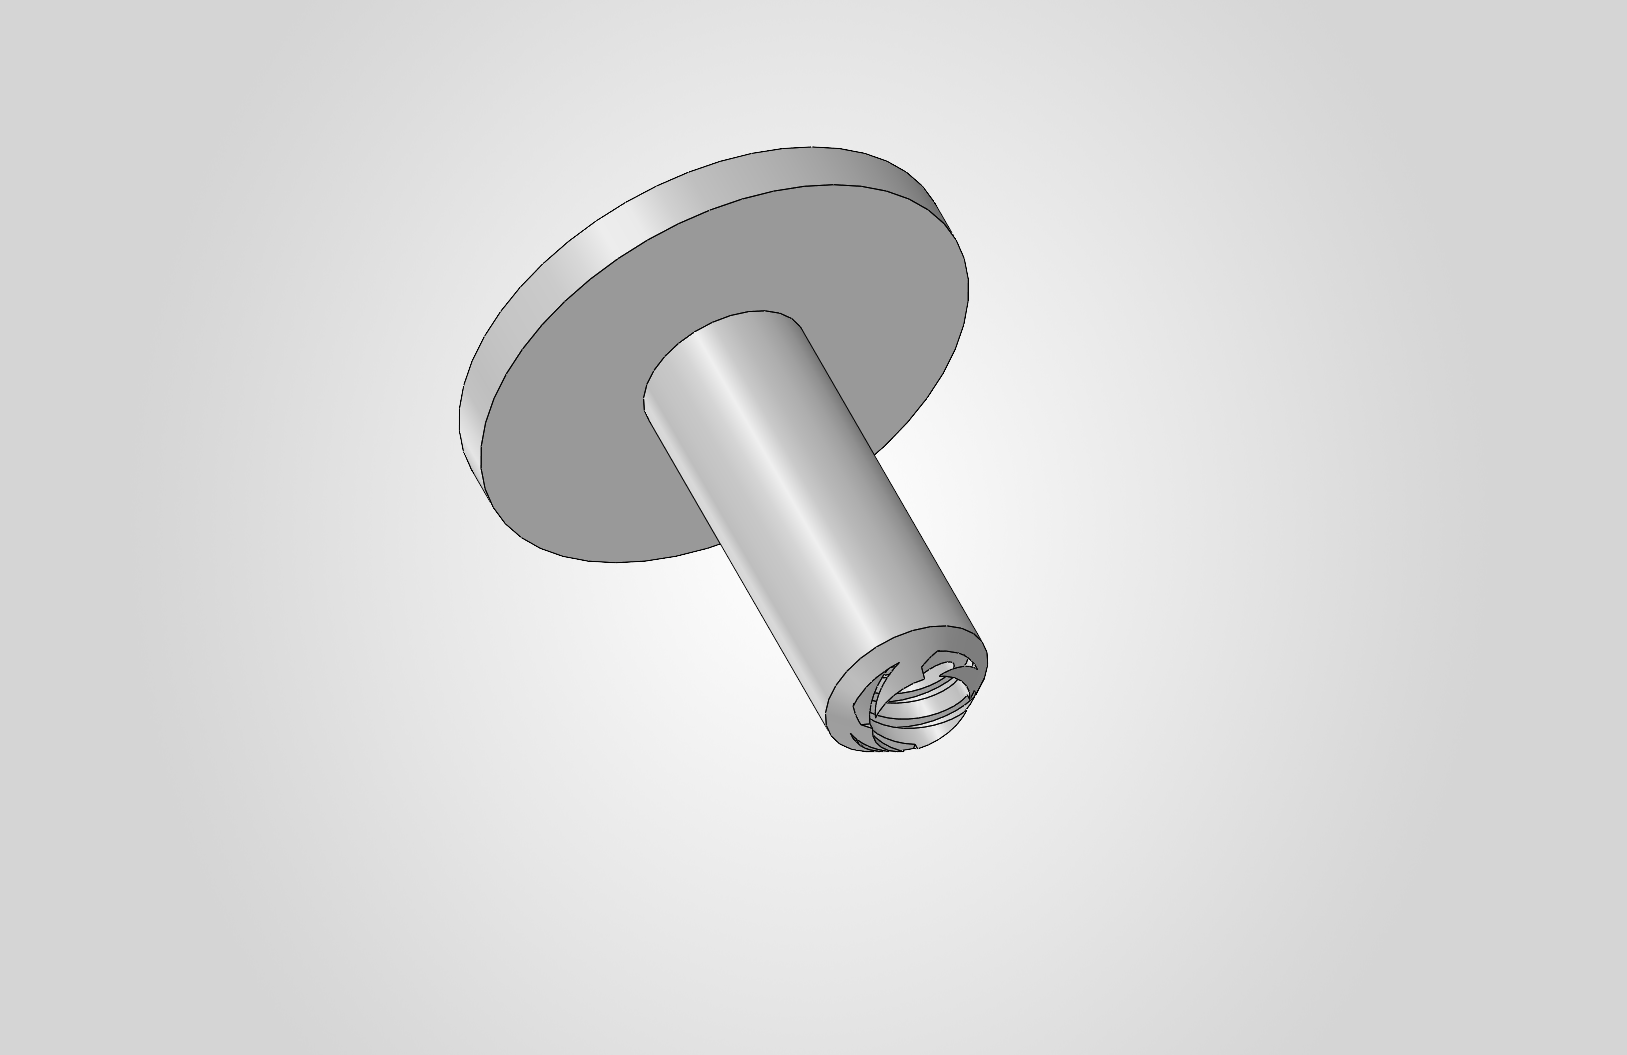
Lead Screw Horn
Provides a mechanical mounting for lead screw
Material: Steel
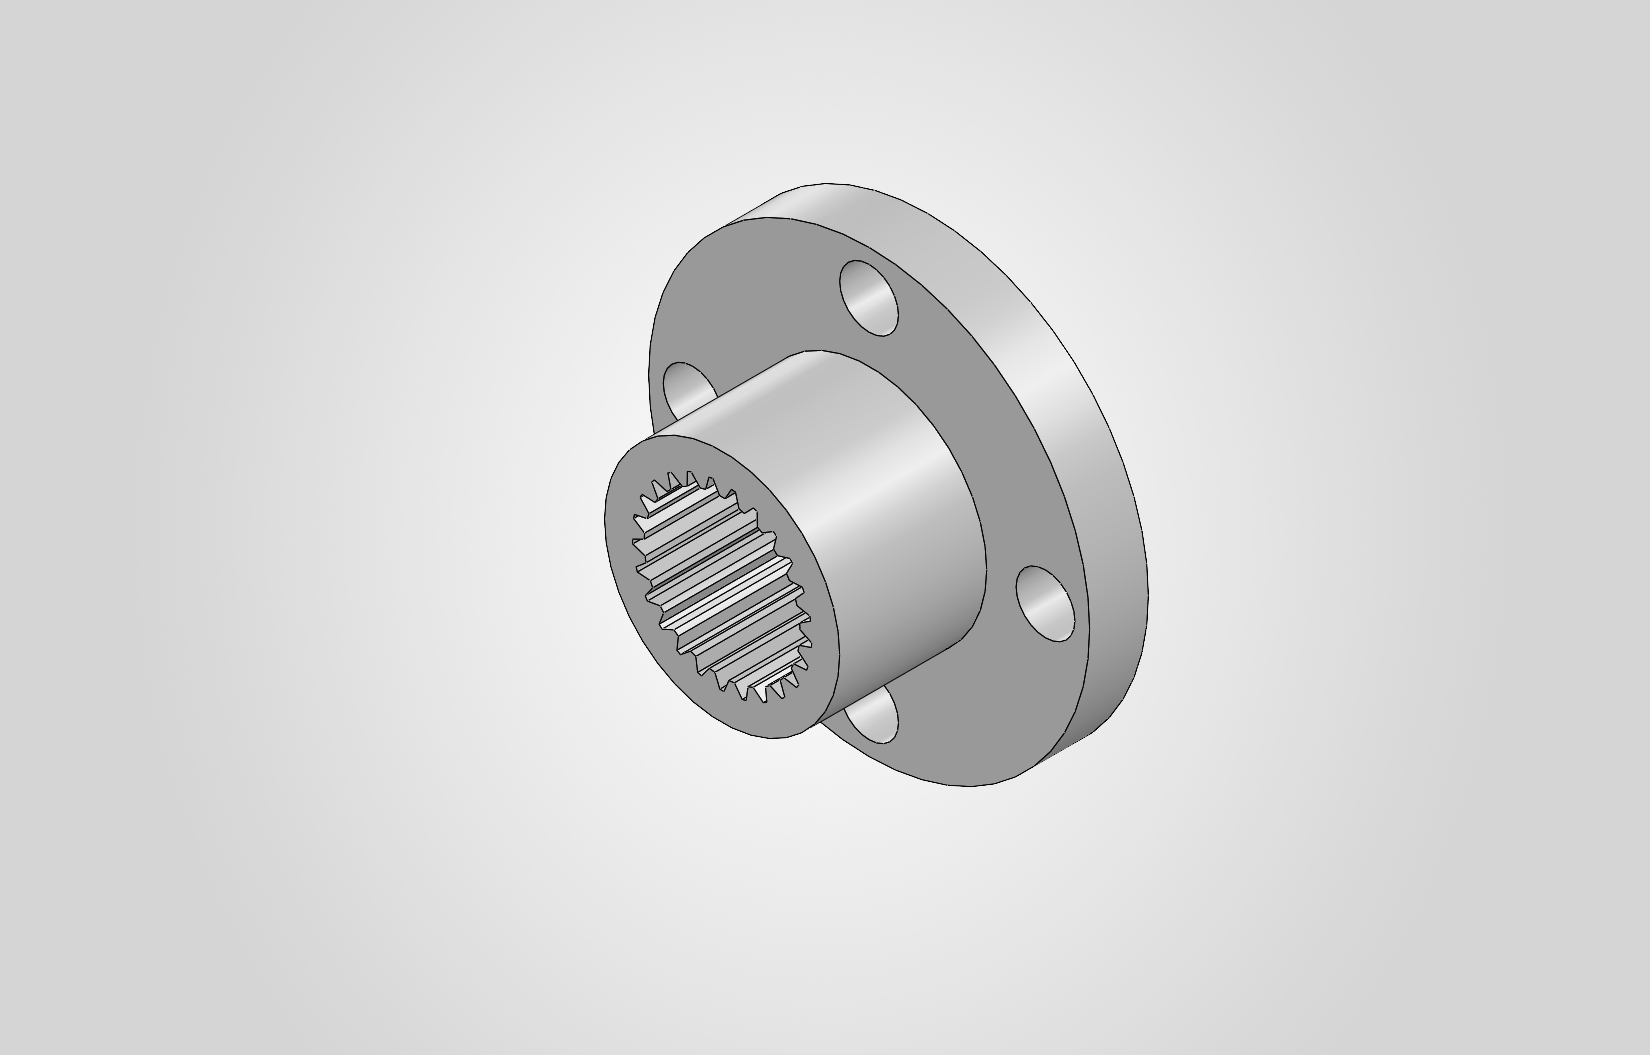
DS3240 Horn
Provides a mechanical mounting for DS3240 Servo motor
Material: Aluminium alloy
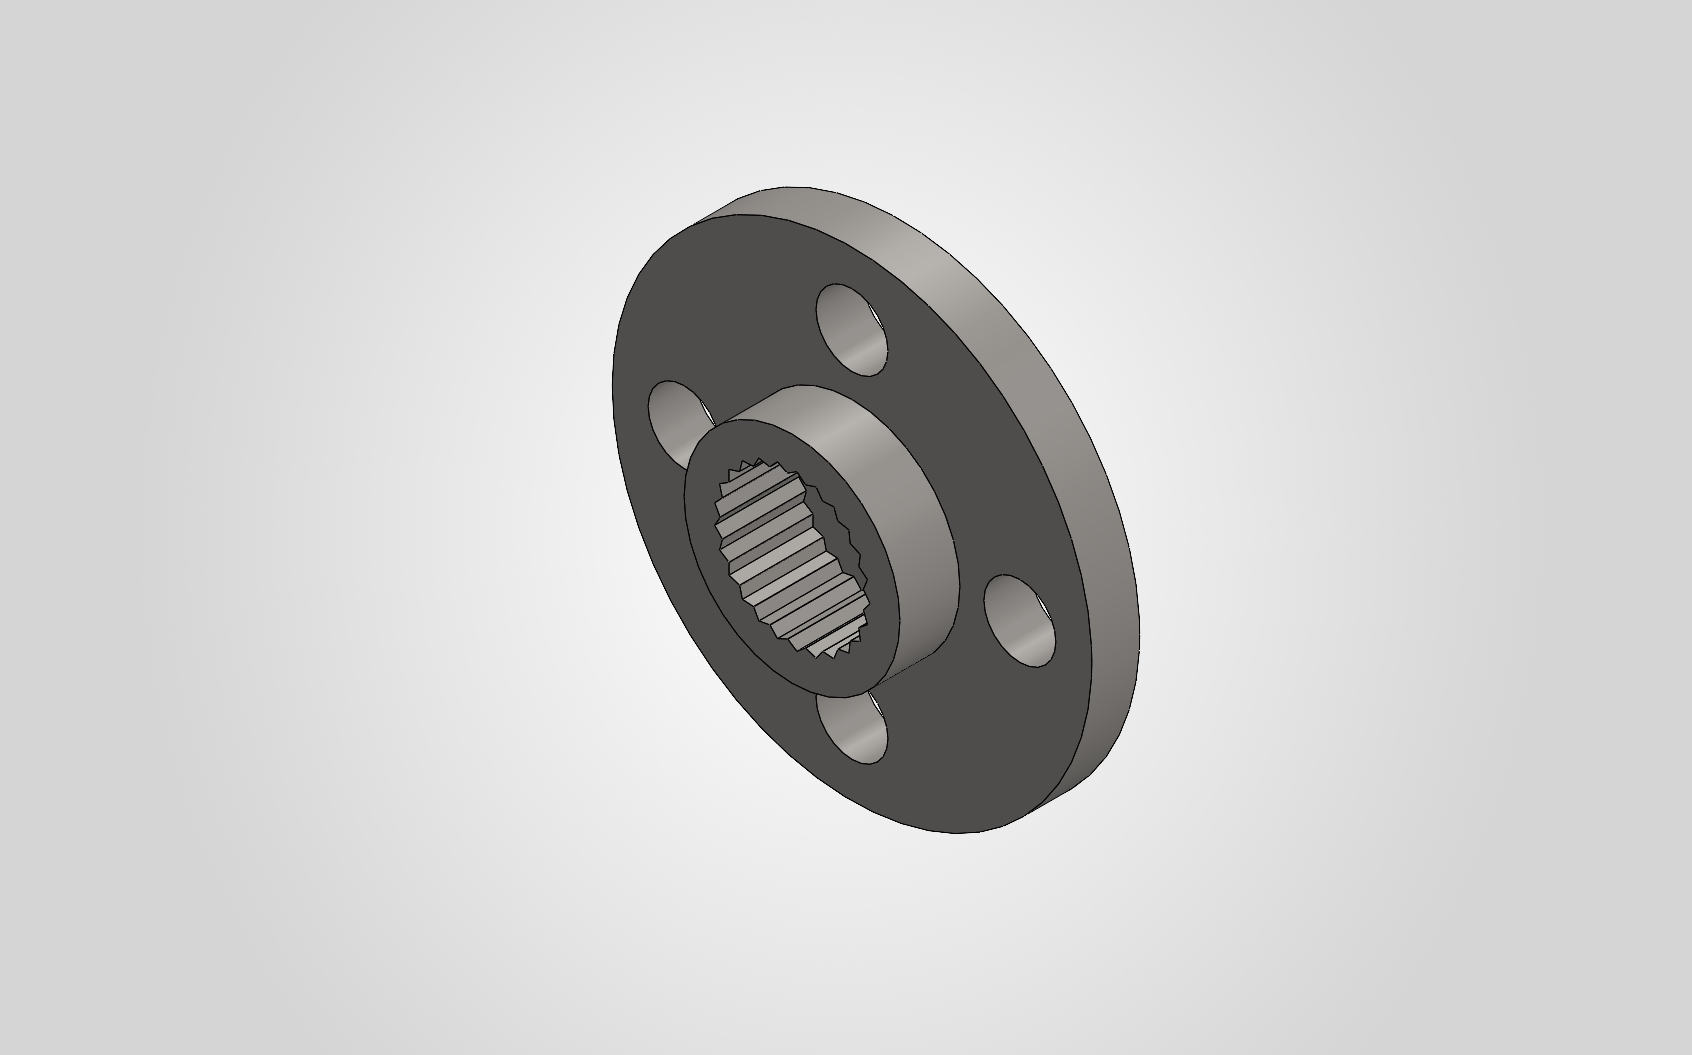
MG 996R Horn
Provides a mechanical mounting for MG996 Servo motor
Material: Aluminium alloy
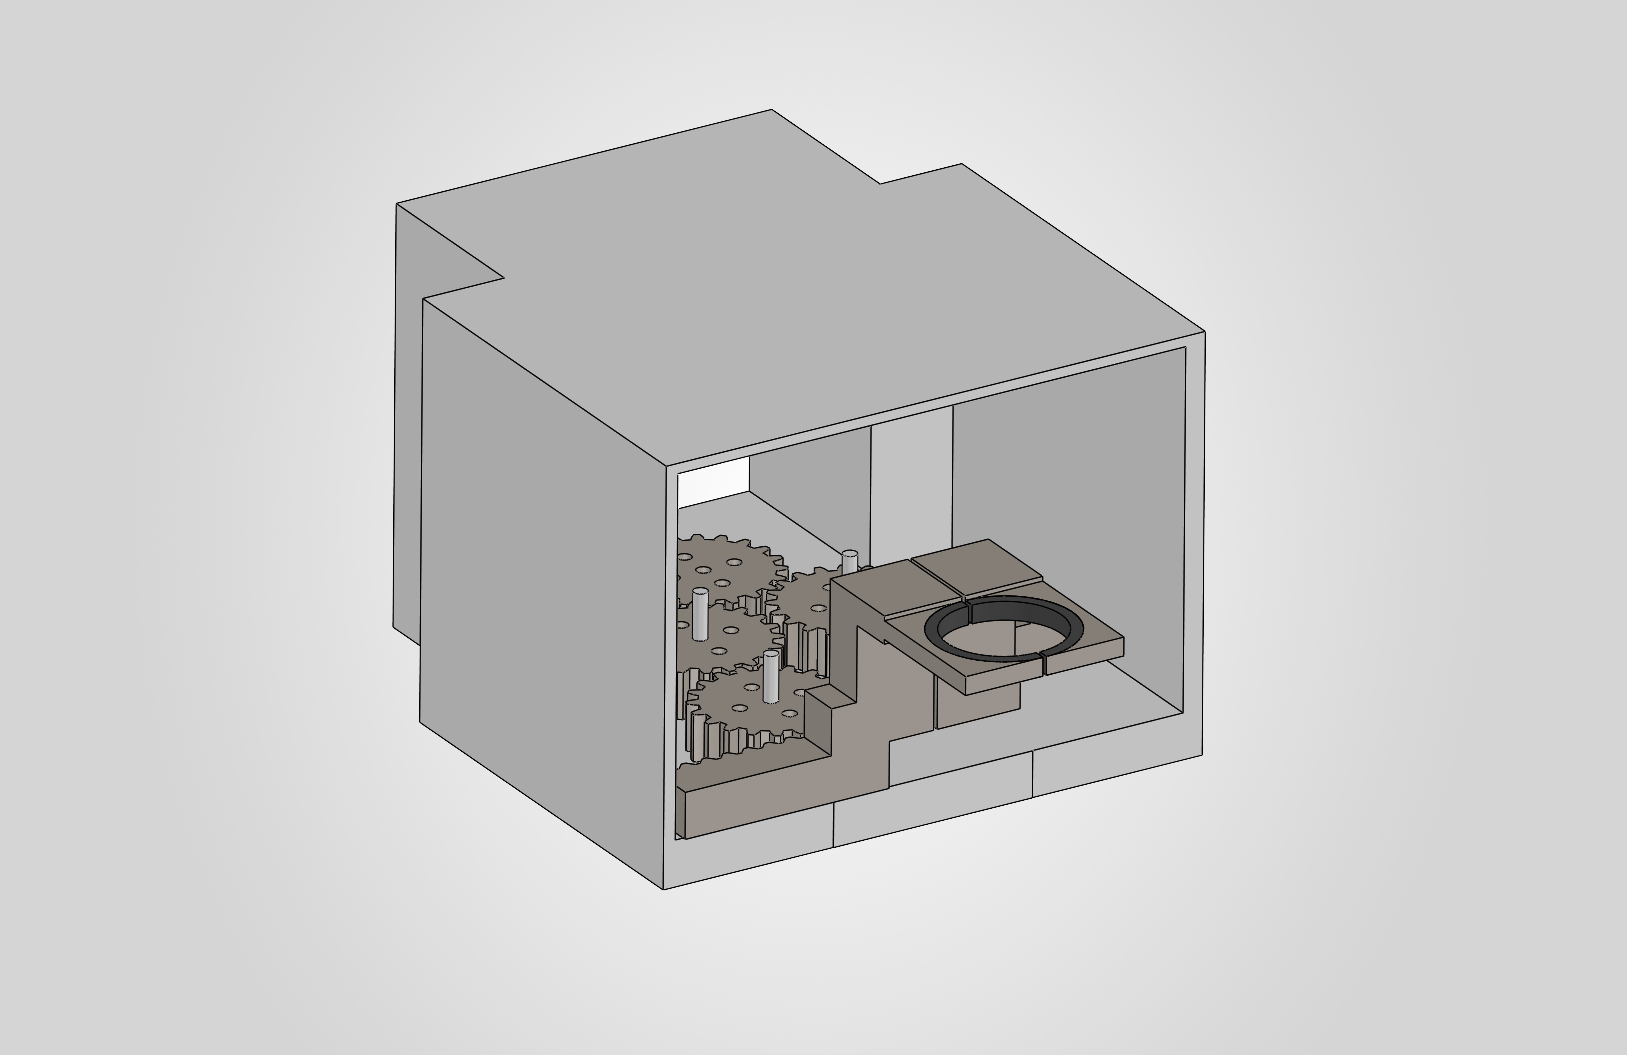
Gripper
Grasps and holds bottles securely during transfer from the rotary table to the collection crate.
Material: Aluminium alloy
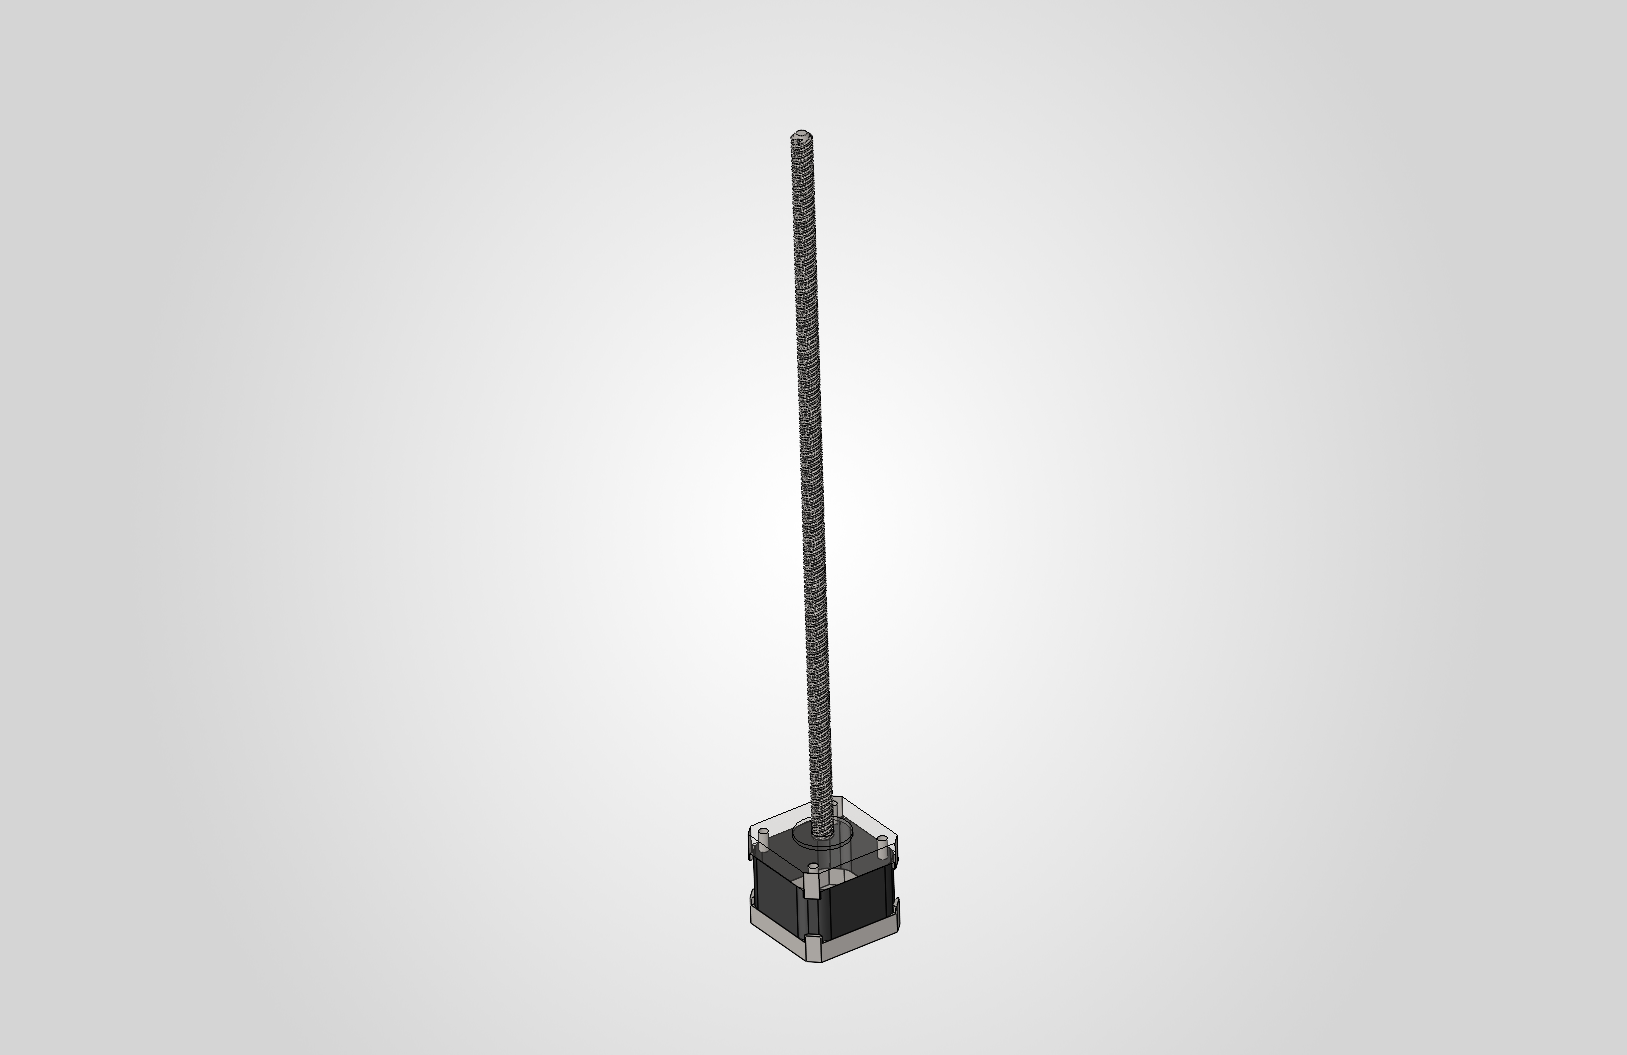
Stepper Motor with Lead Screw
Provide transaltional motion
Material: Aluminium alloy casing
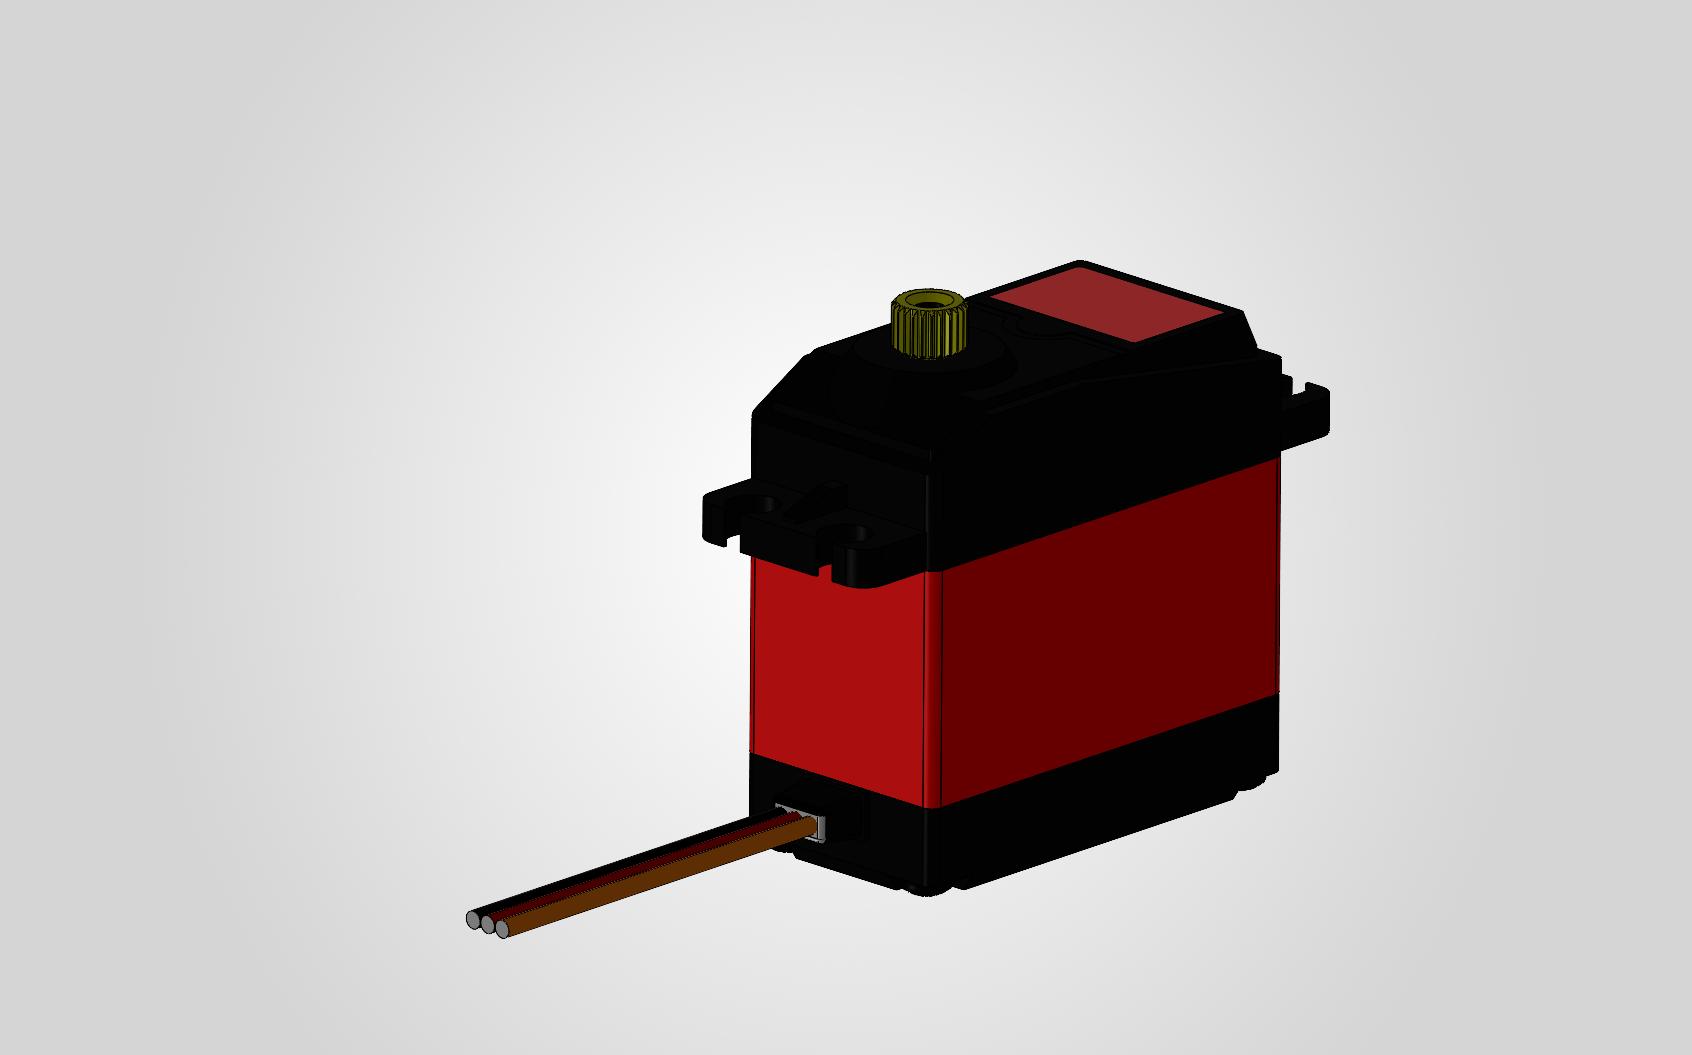
DS3240 Servomotor
Provides rotational motion
Material: Aluminium alloy casing
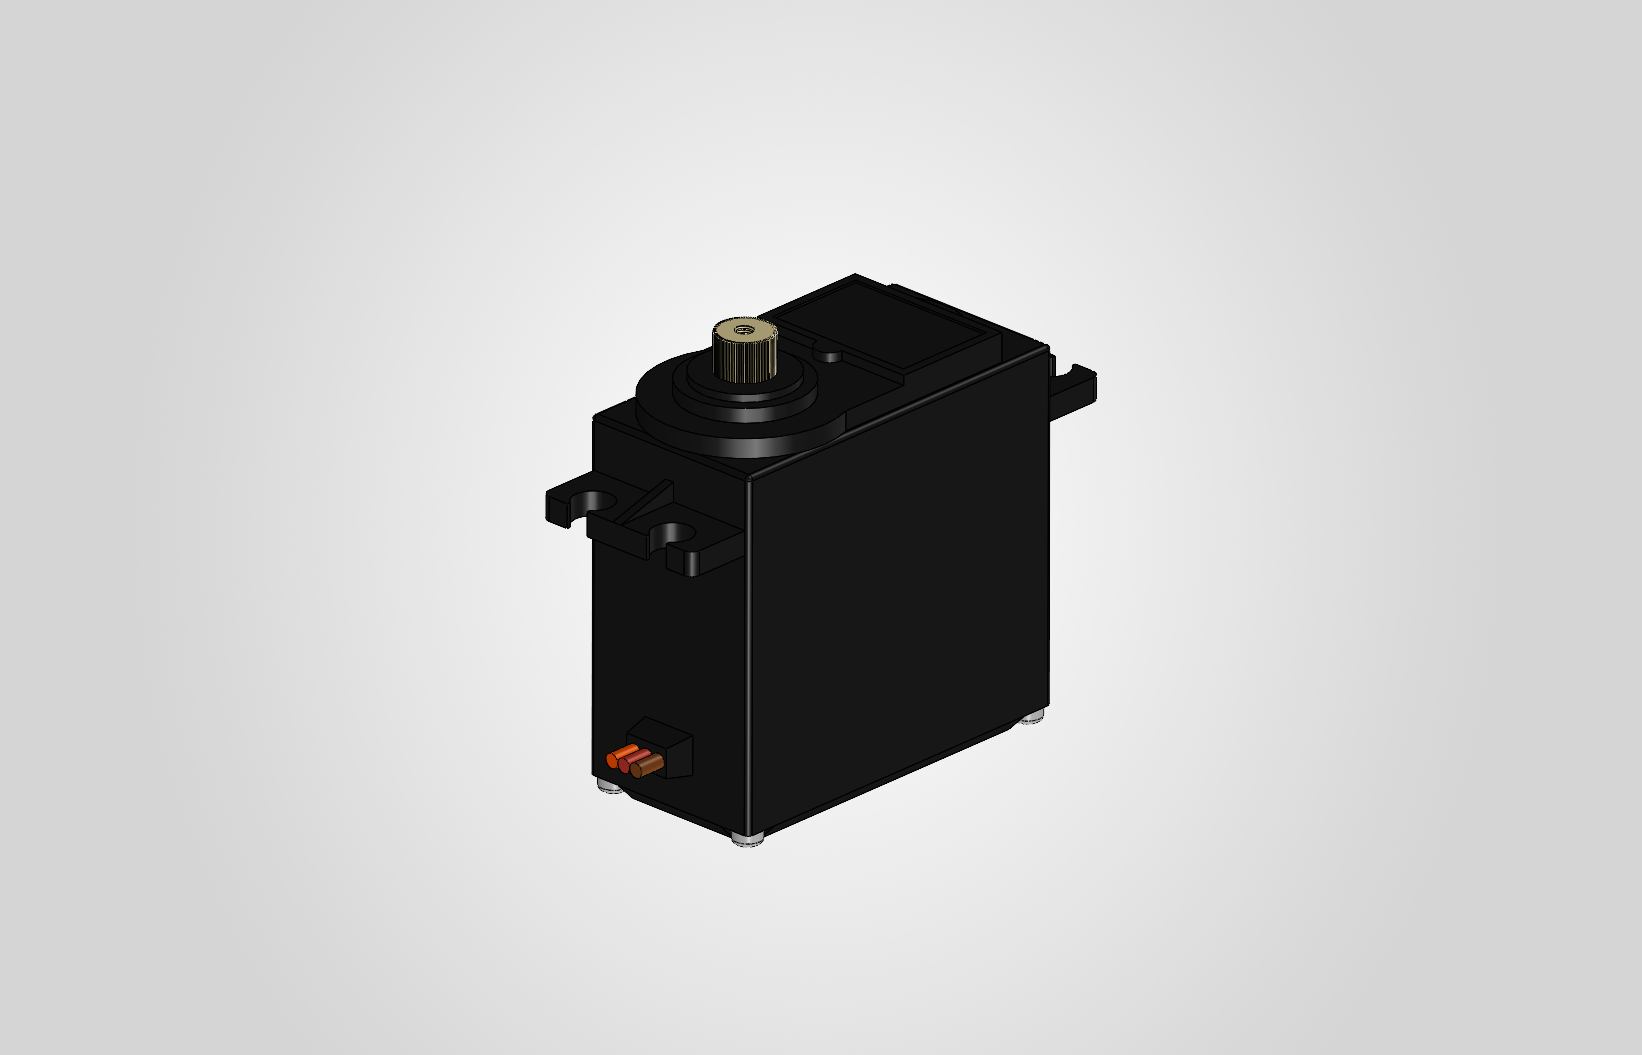
MG 996R DC Motor
Provides rotational motion
Material: Aluminium alloy casing